6 × 1000 W EtherCAT servos
AC servo motors with holding brake, 3.2 Nm rated torque and three times that as peak — synchronised over EtherCAT for jitter-free motion.
In development · Fourth generation
The 6-DOF motion platform, engineered from the ground up.
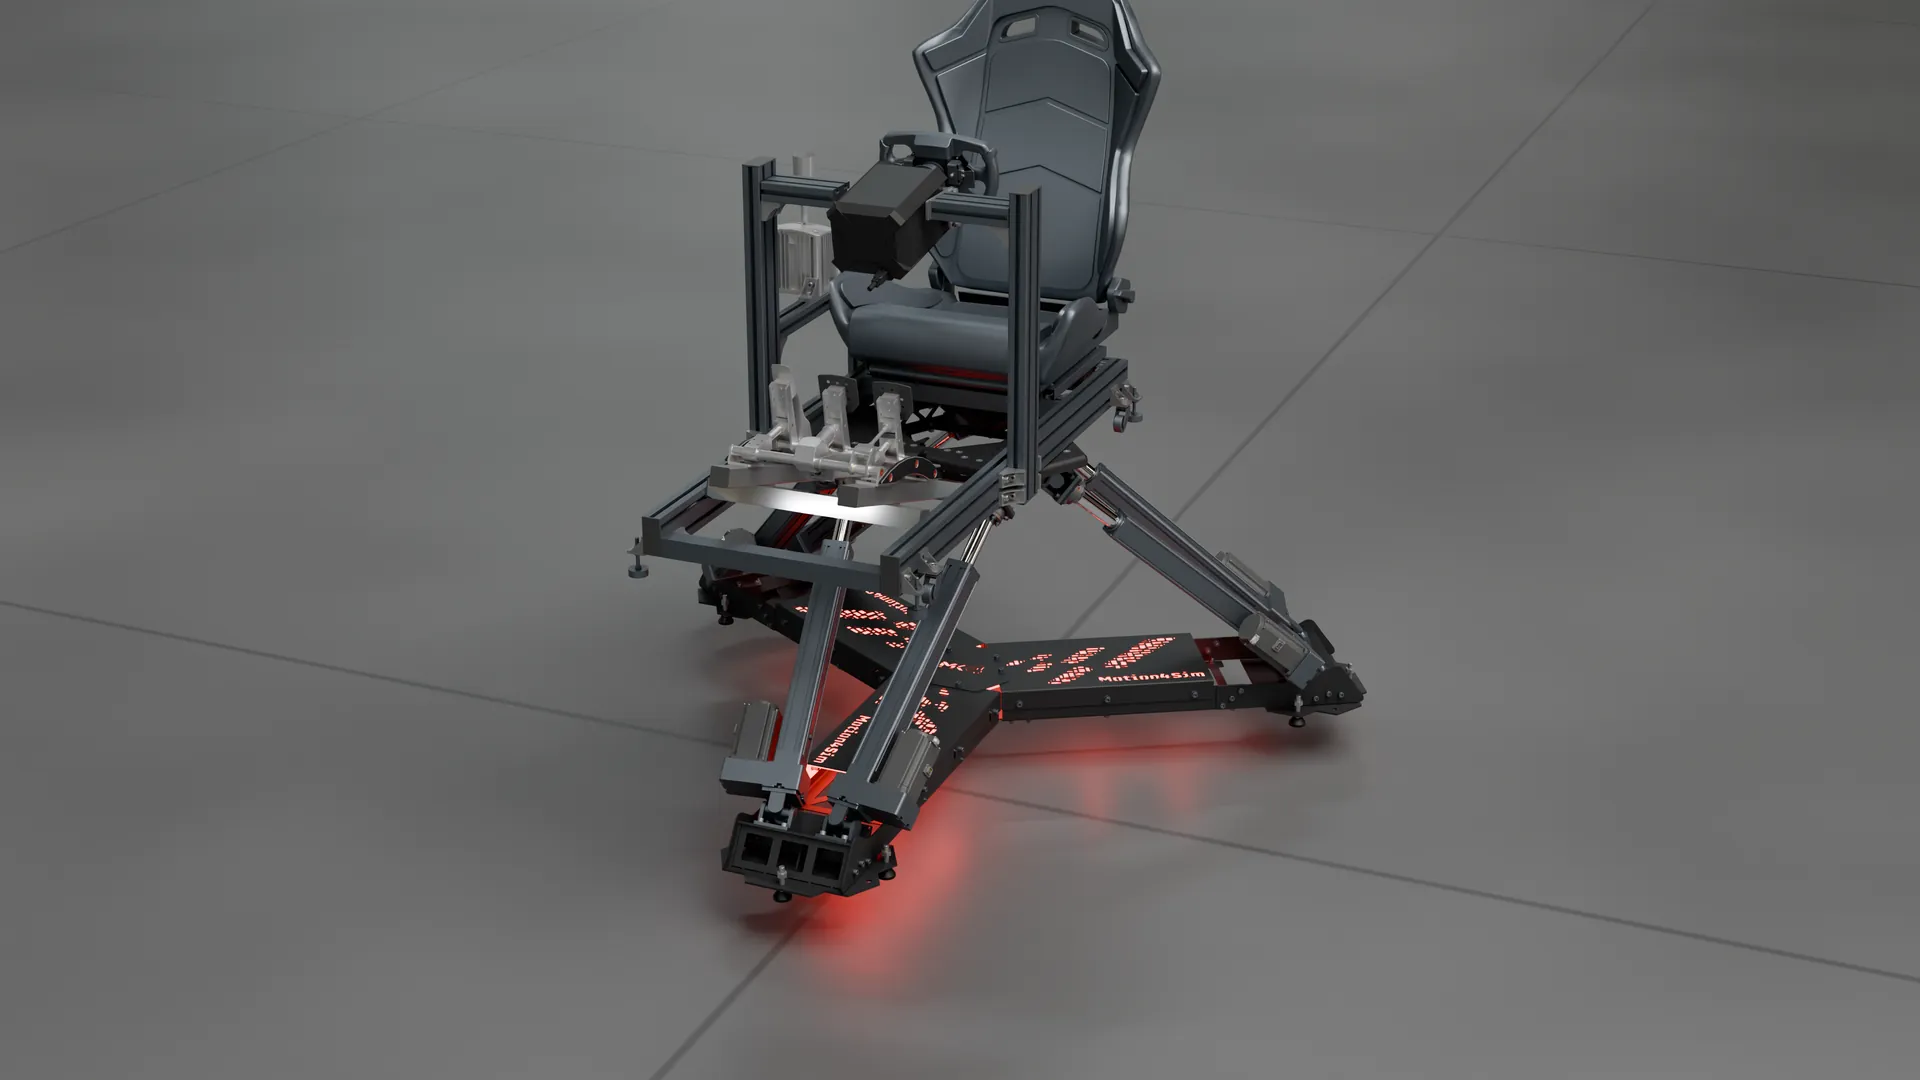
Six 1000 W EtherCAT servo actuators, 400 mm stroke and a laser-cut steel hexapod — driven by the Motion4Sim controller.
MK4 — Make 4
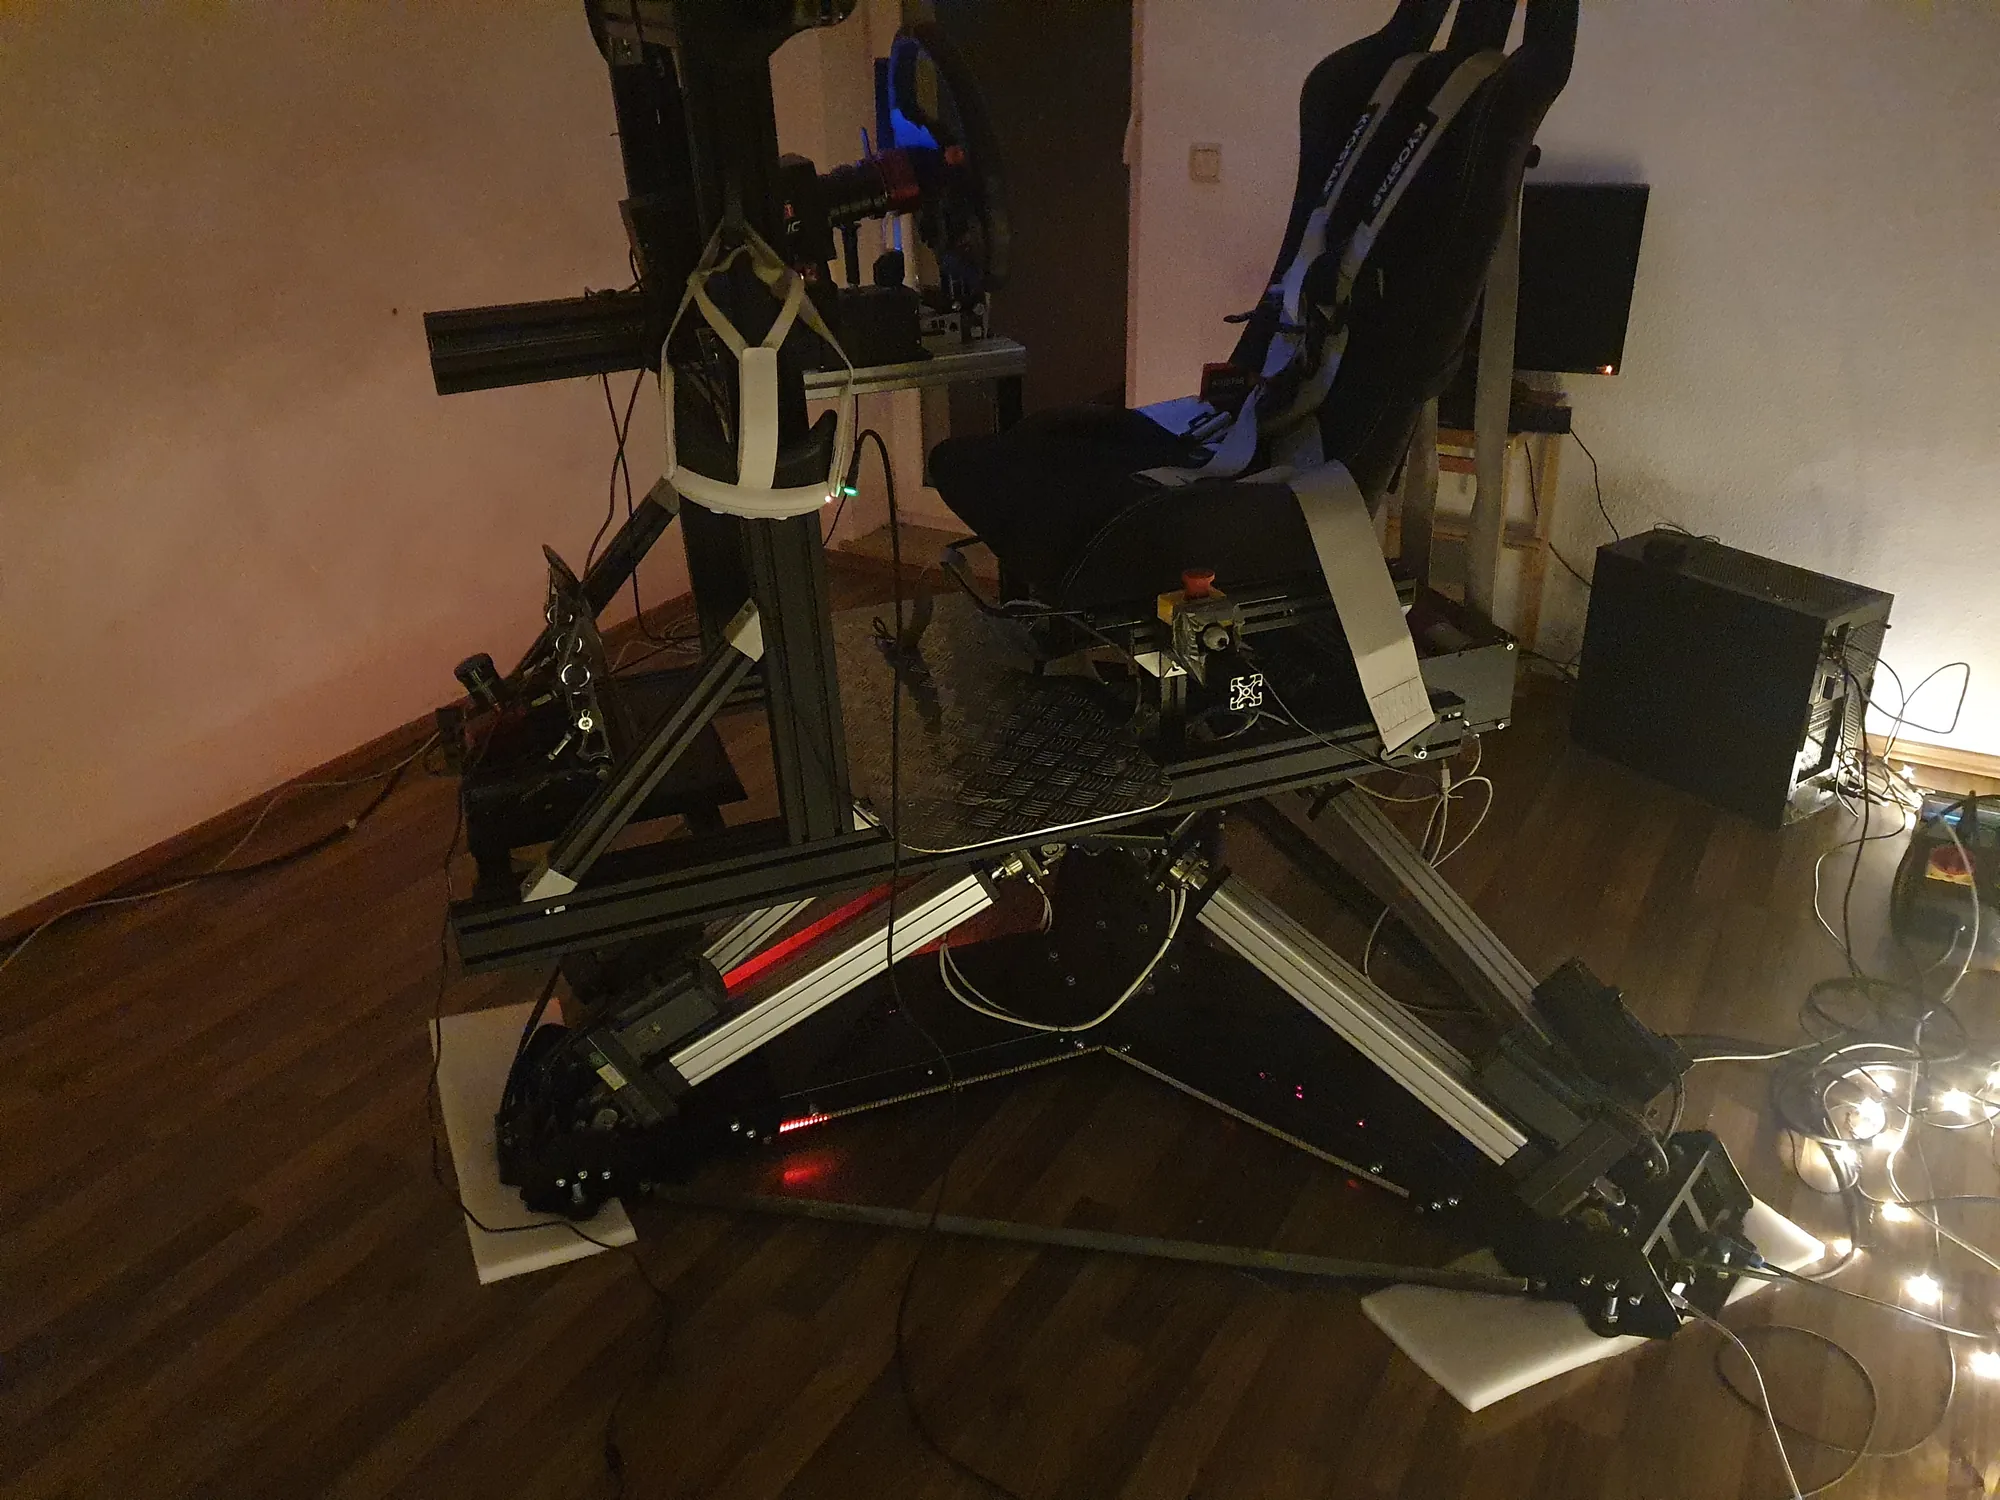
The MK4 is a Stewart platform: six linear actuators carry the cockpit on gimbal joints. Surge, sway, heave, roll, pitch and yaw are available independently and in any combination — with the instant response of servo-driven ball screws.
Every part was generated parametrically in CAD and every pose checked: the kinematics, the joint angles and the actuator forces of the MK4 were computed for millions of positions before the first sheet was cut.
Engineering
Industrial drive technology, precise joints and a steel structure without compromises.
AC servo motors with holding brake, 3.2 Nm rated torque and three times that as peak — synchronised over EtherCAT for jitter-free motion.
Ø16 mm ball screw with 10 mm lead, 400 mm stroke and up to 500 mm/s. 1.8 kN continuous and 5.4 kN peak force per actuator.
Twelve universal joints with a 40° cone. At the top, ZKLF angular-contact thrust bearings free the rod rotation — no binding, no play.
S235 steel in 2, 3 and 5 mm, tab-and-slot base boxes and a bolted top frame. Rigid, quiet and built to last.
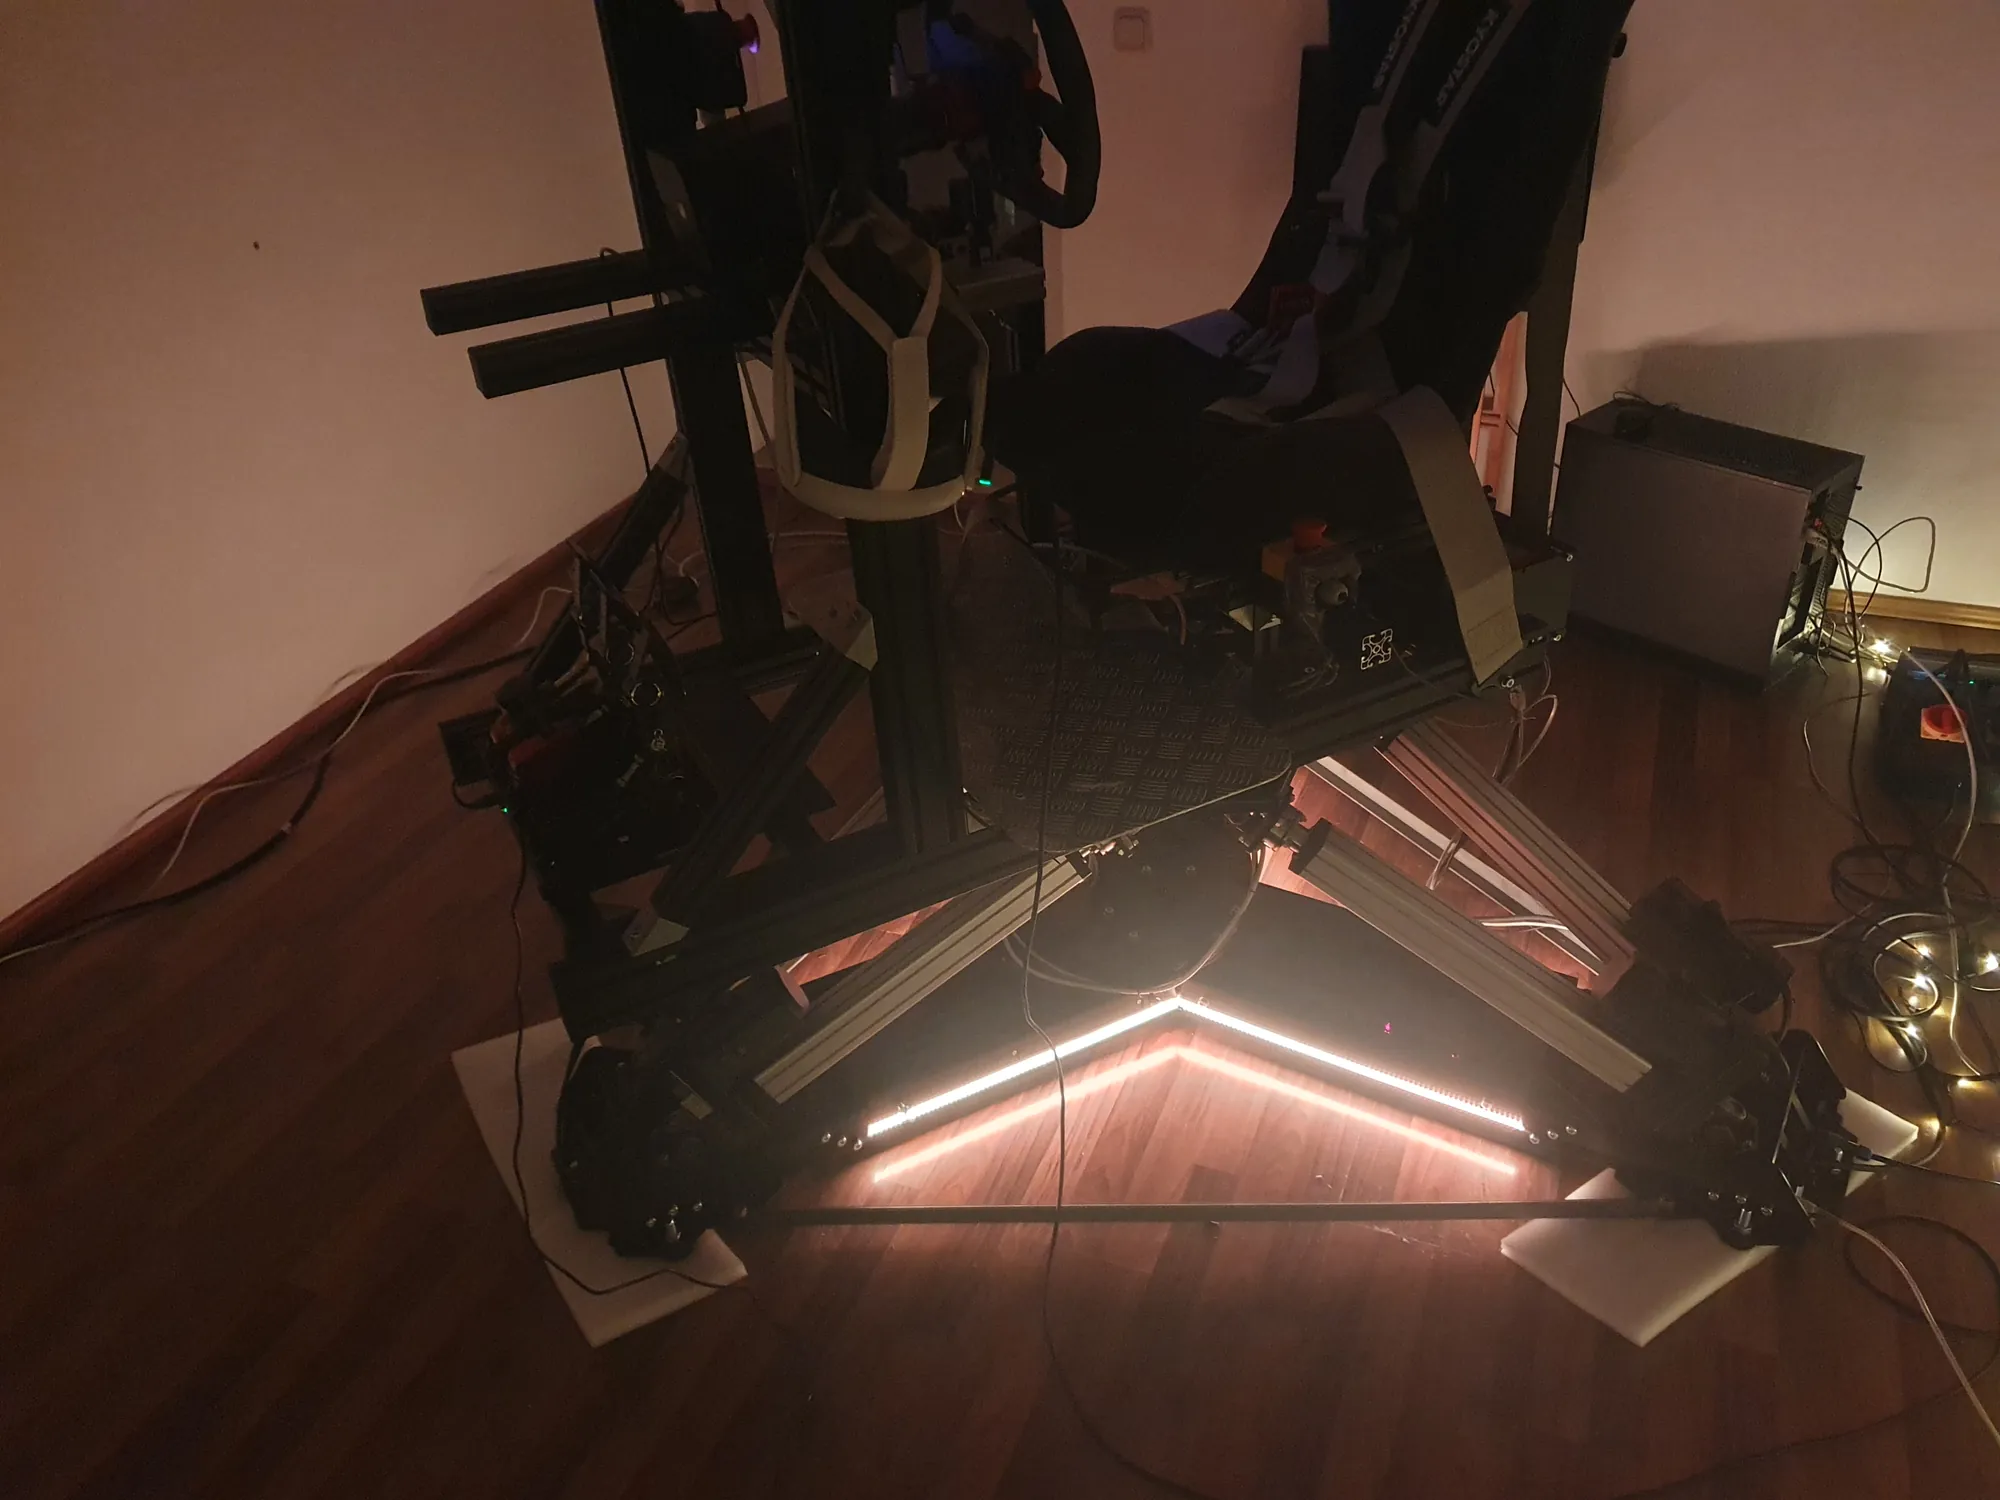
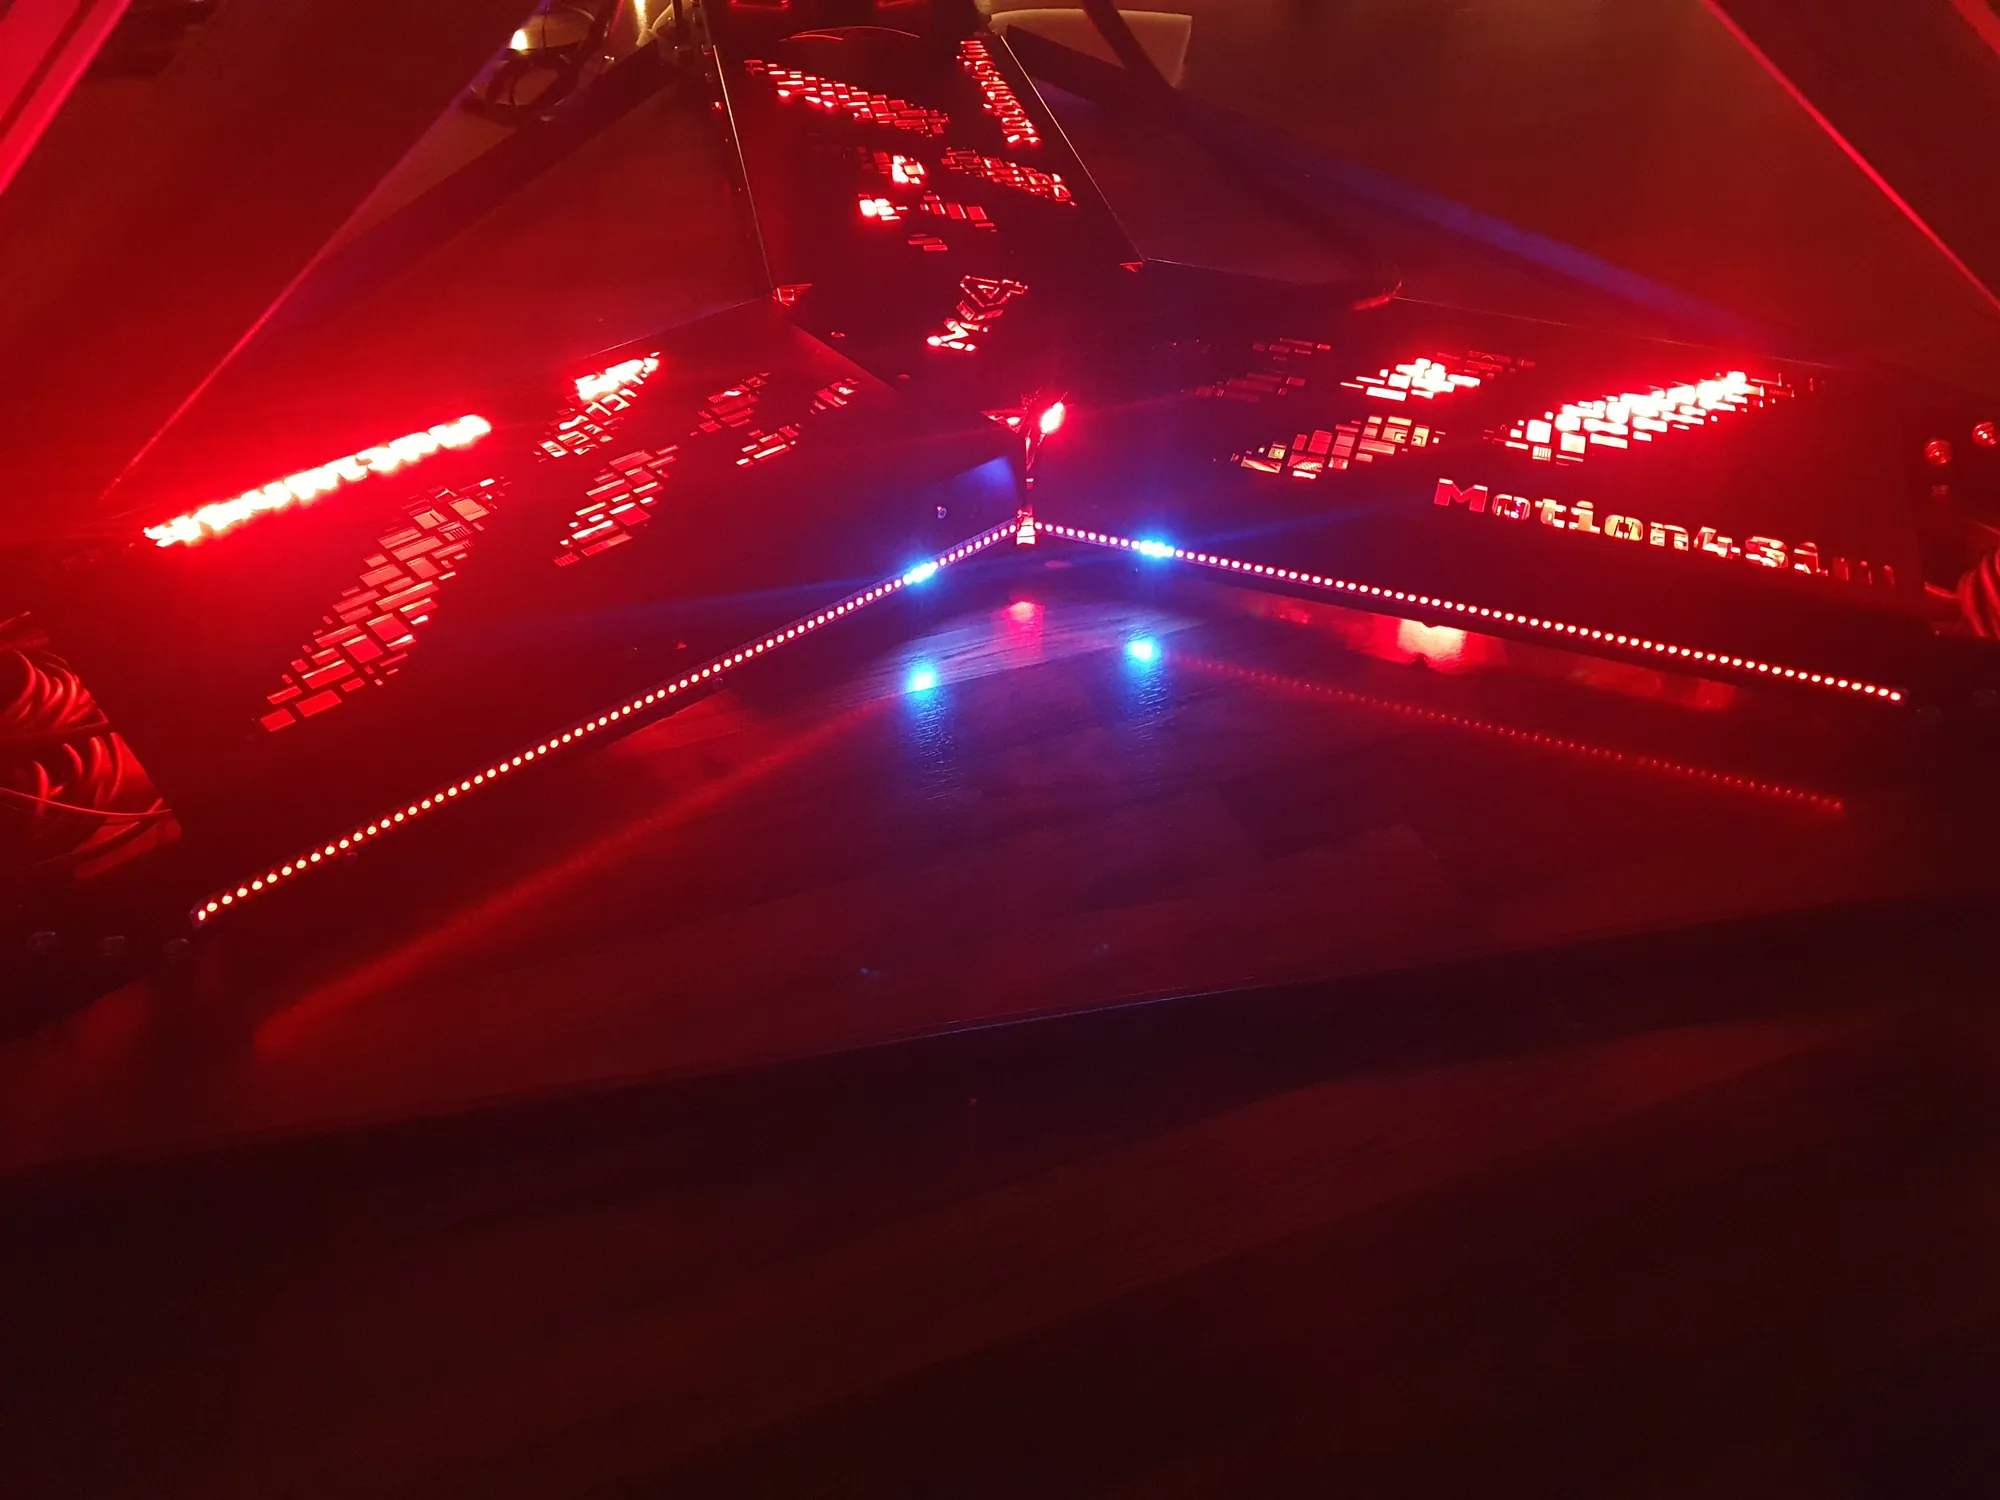
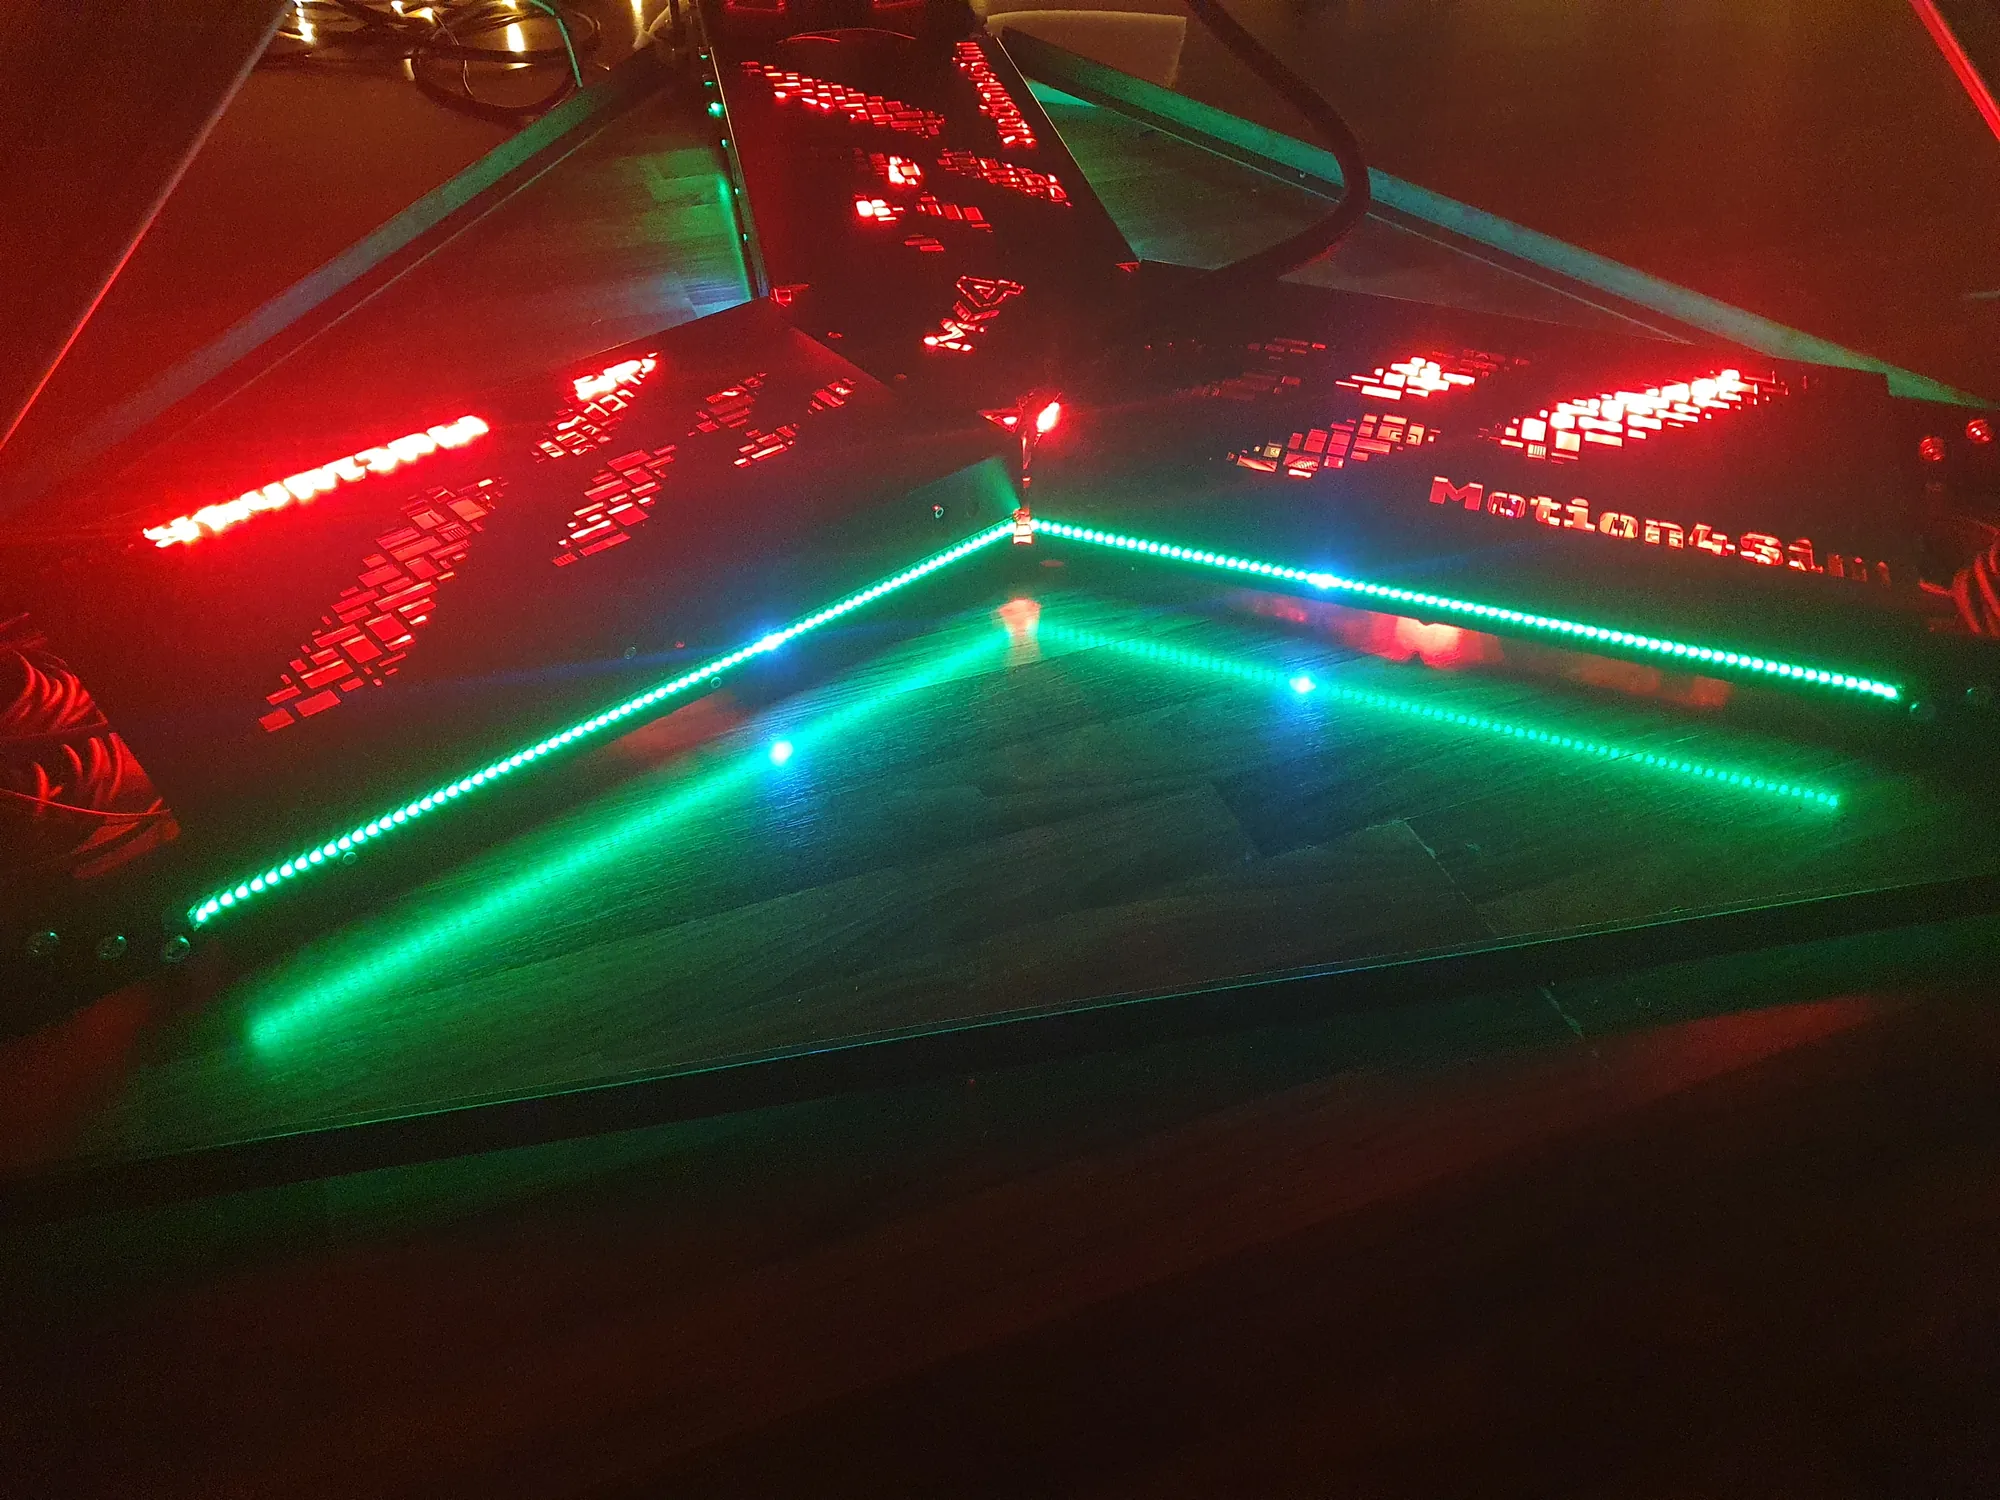
LED strips under the base covers shine through the MK4 and Motion4Sim cut-outs and light the floor around the rig.
Our own controller and Dashboard: MK4 preset with live 3D view, works with SimTools, FlyPT Mover, Sim Racing Studio and SimHub.
Six degrees of freedom
Rendered from the CAD model with the real kinematics — each clip shows one axis, the camera flies around the rig.
−270 / +355 mm
Forwards and backwards — acceleration and braking.
±280 mm
Sideways — lateral forces in corners.
−315 / +255 mm
Up and down — kerbs, bumps and crests.
±30°
Tilt about the longitudinal axis — body roll and banking.
±30°
Nose up and down — dive under braking, squat under power.
±30°
Rotation about the vertical axis — slides, drifts and traction loss.
Translations: single-axis limits of the rig geometry (actuator stroke and 40° gimbal cone). Rotations are limited to ±30° on all axes for stability. In combined motion the controller keeps the platform inside the safe workspace.
Interactive
The real CAD model with the real kinematics, computed live in your browser. Move the sliders — every actuator, joint and gimbal follows.
Loading CAD model 0 %
Drag to orbit · scroll or pinch to zoom · right-drag to pan
Dimensions
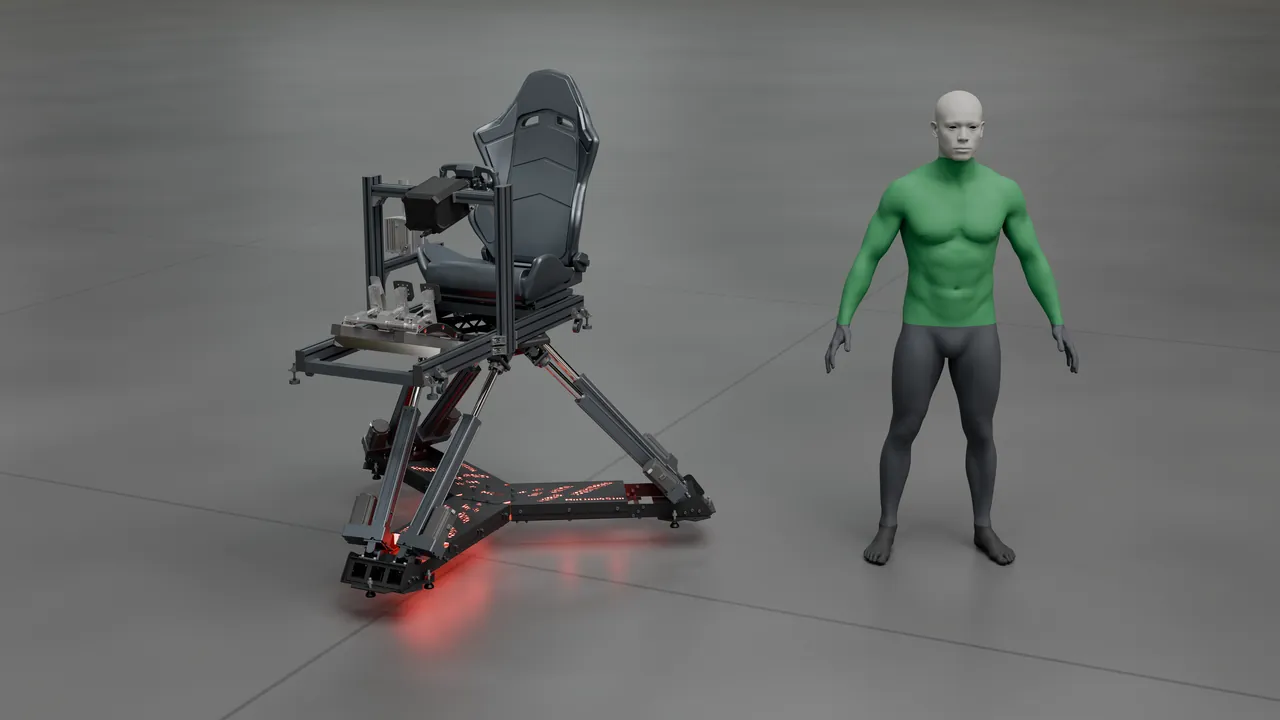
Measured directly on the CAD model — retracted, neutral and fully extended, with or without cockpit, next to a 1.80 m person.
All values in millimetres, floor = underside of the levelling feet. Cockpit shown as an example set-up.
Gallery
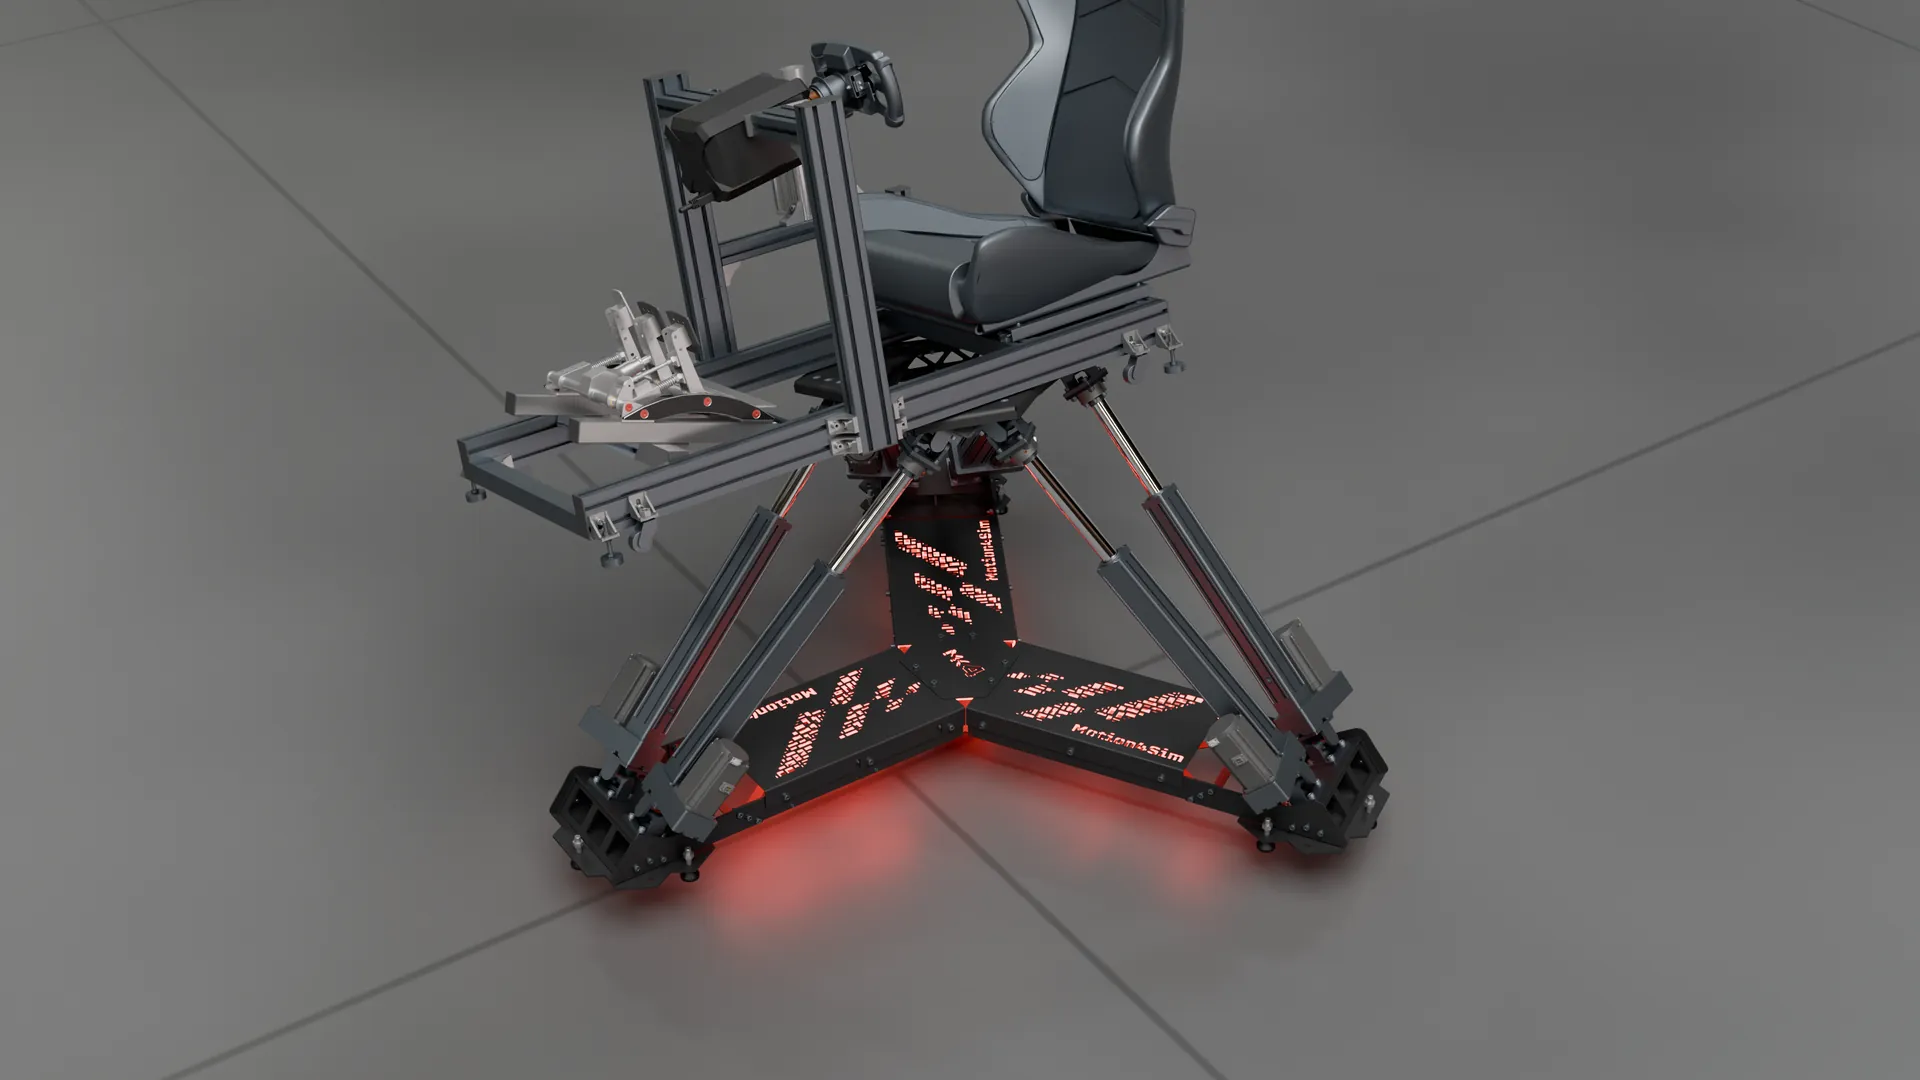
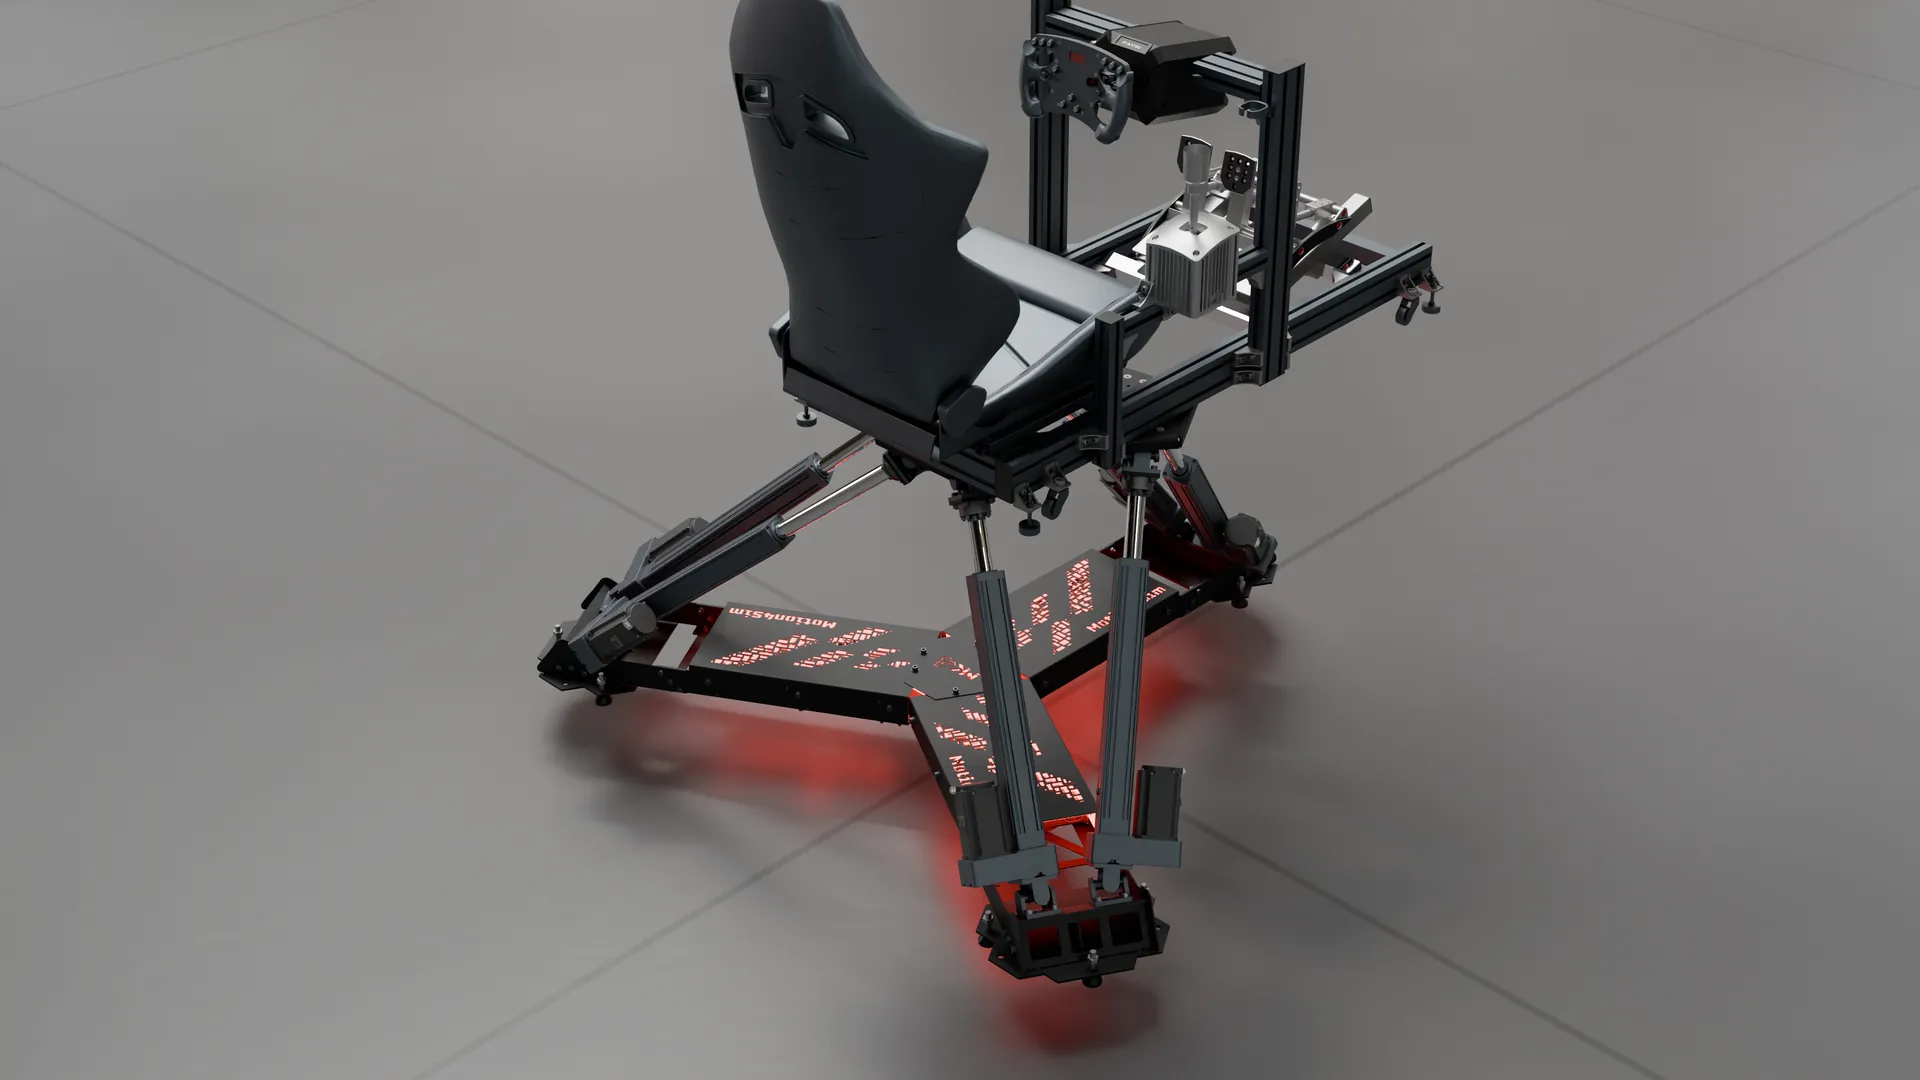
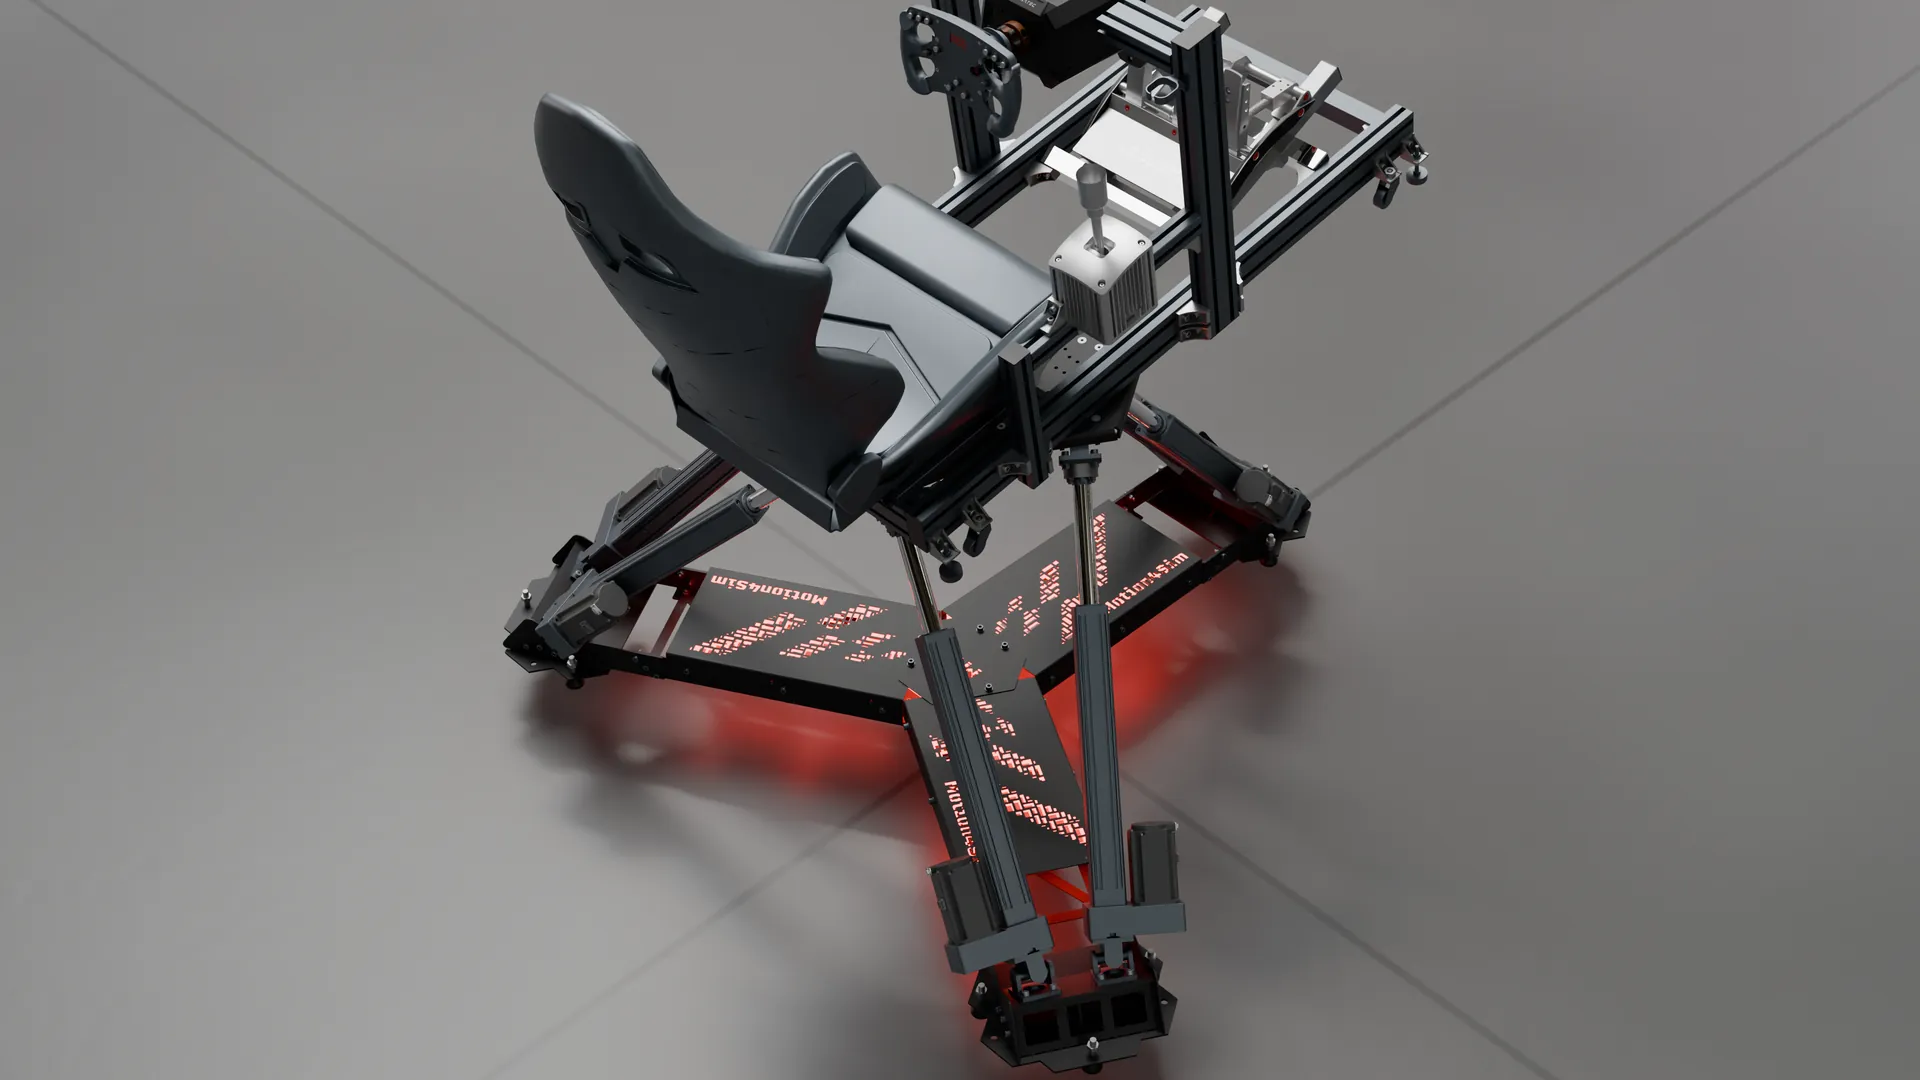
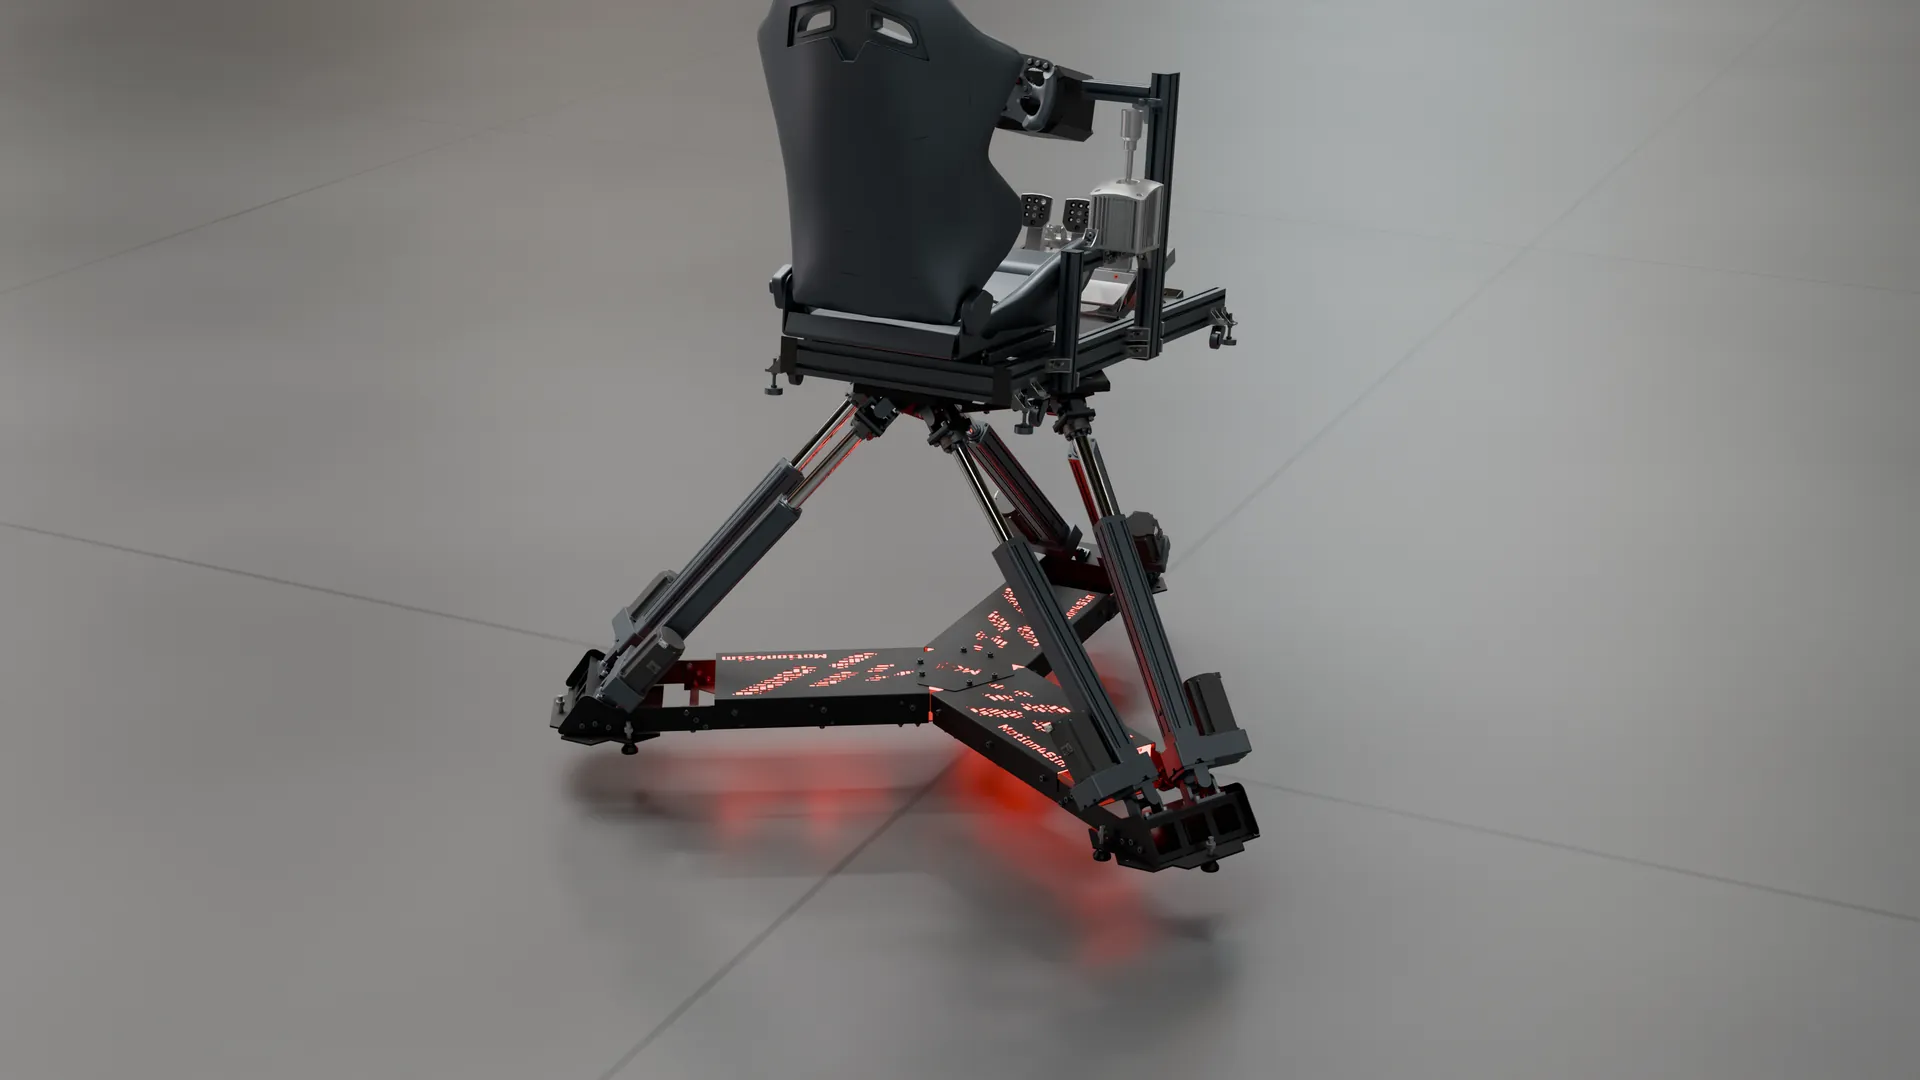
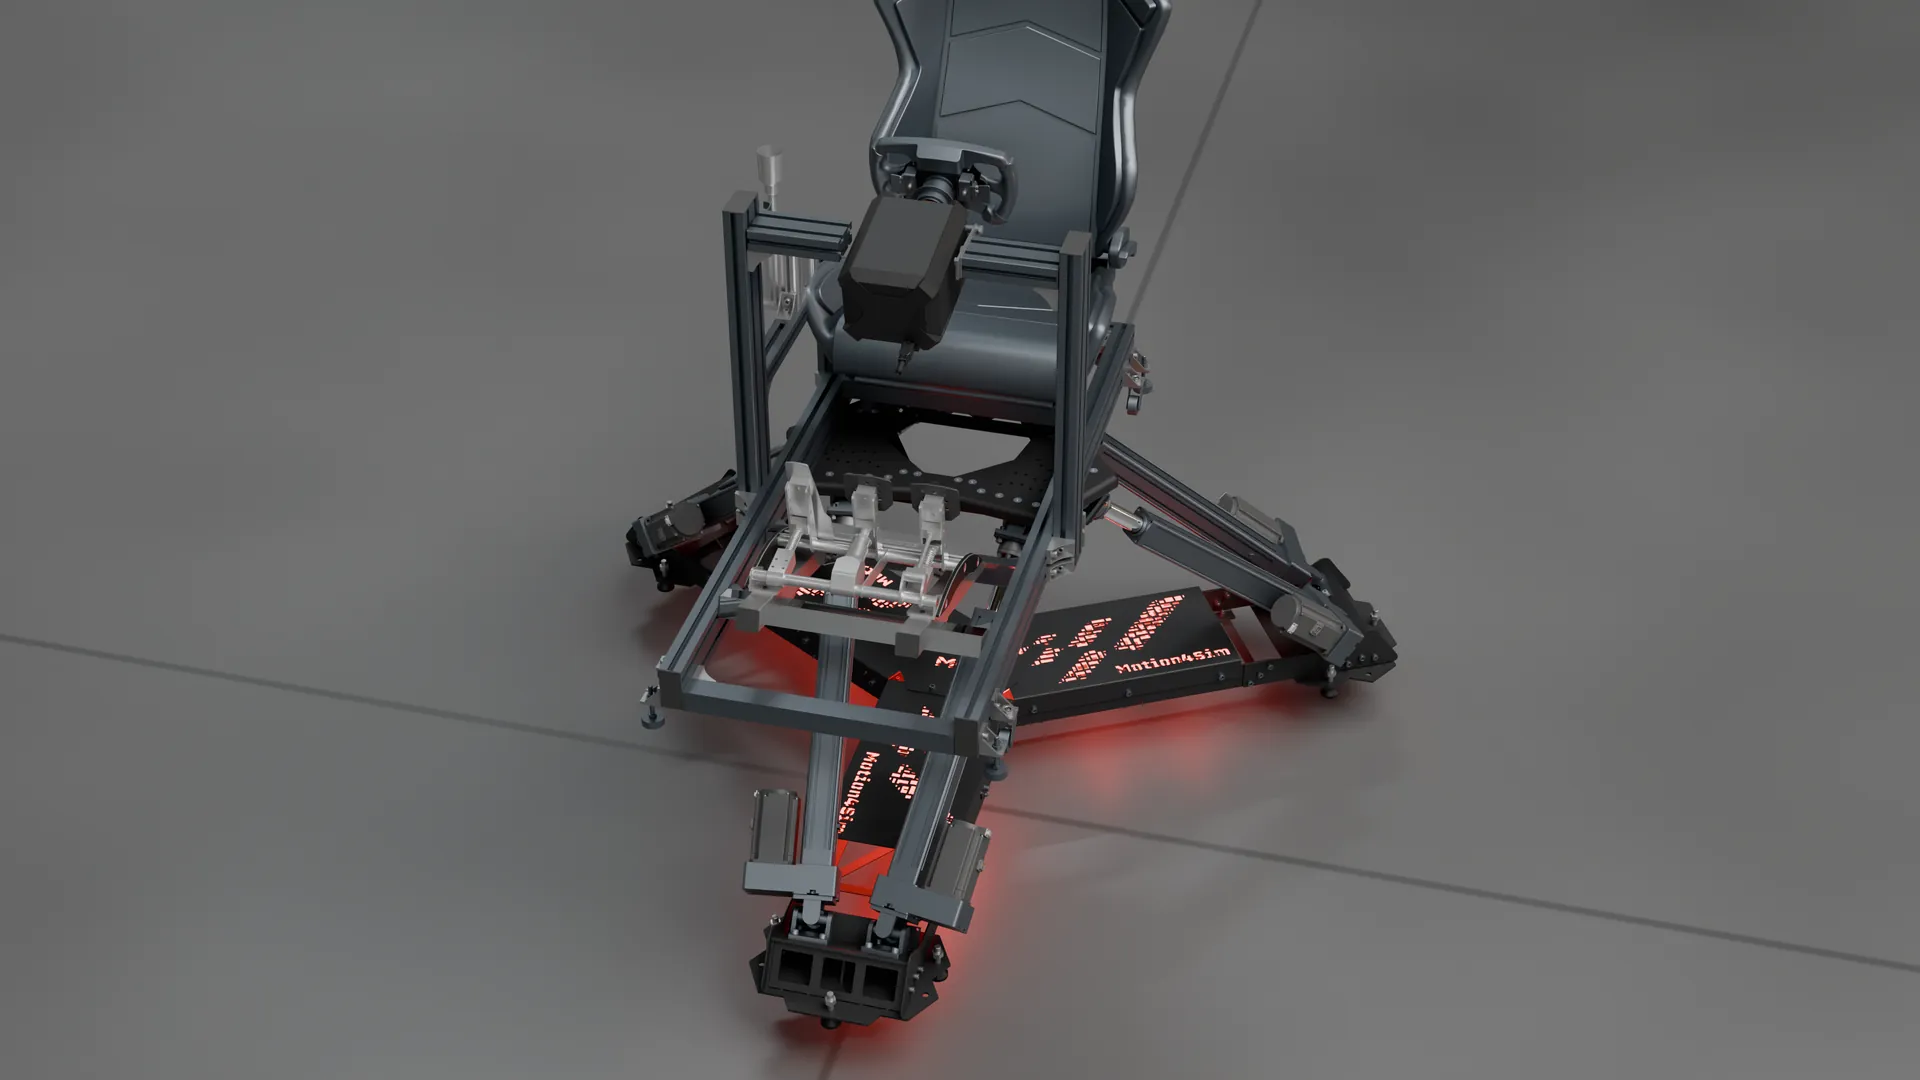
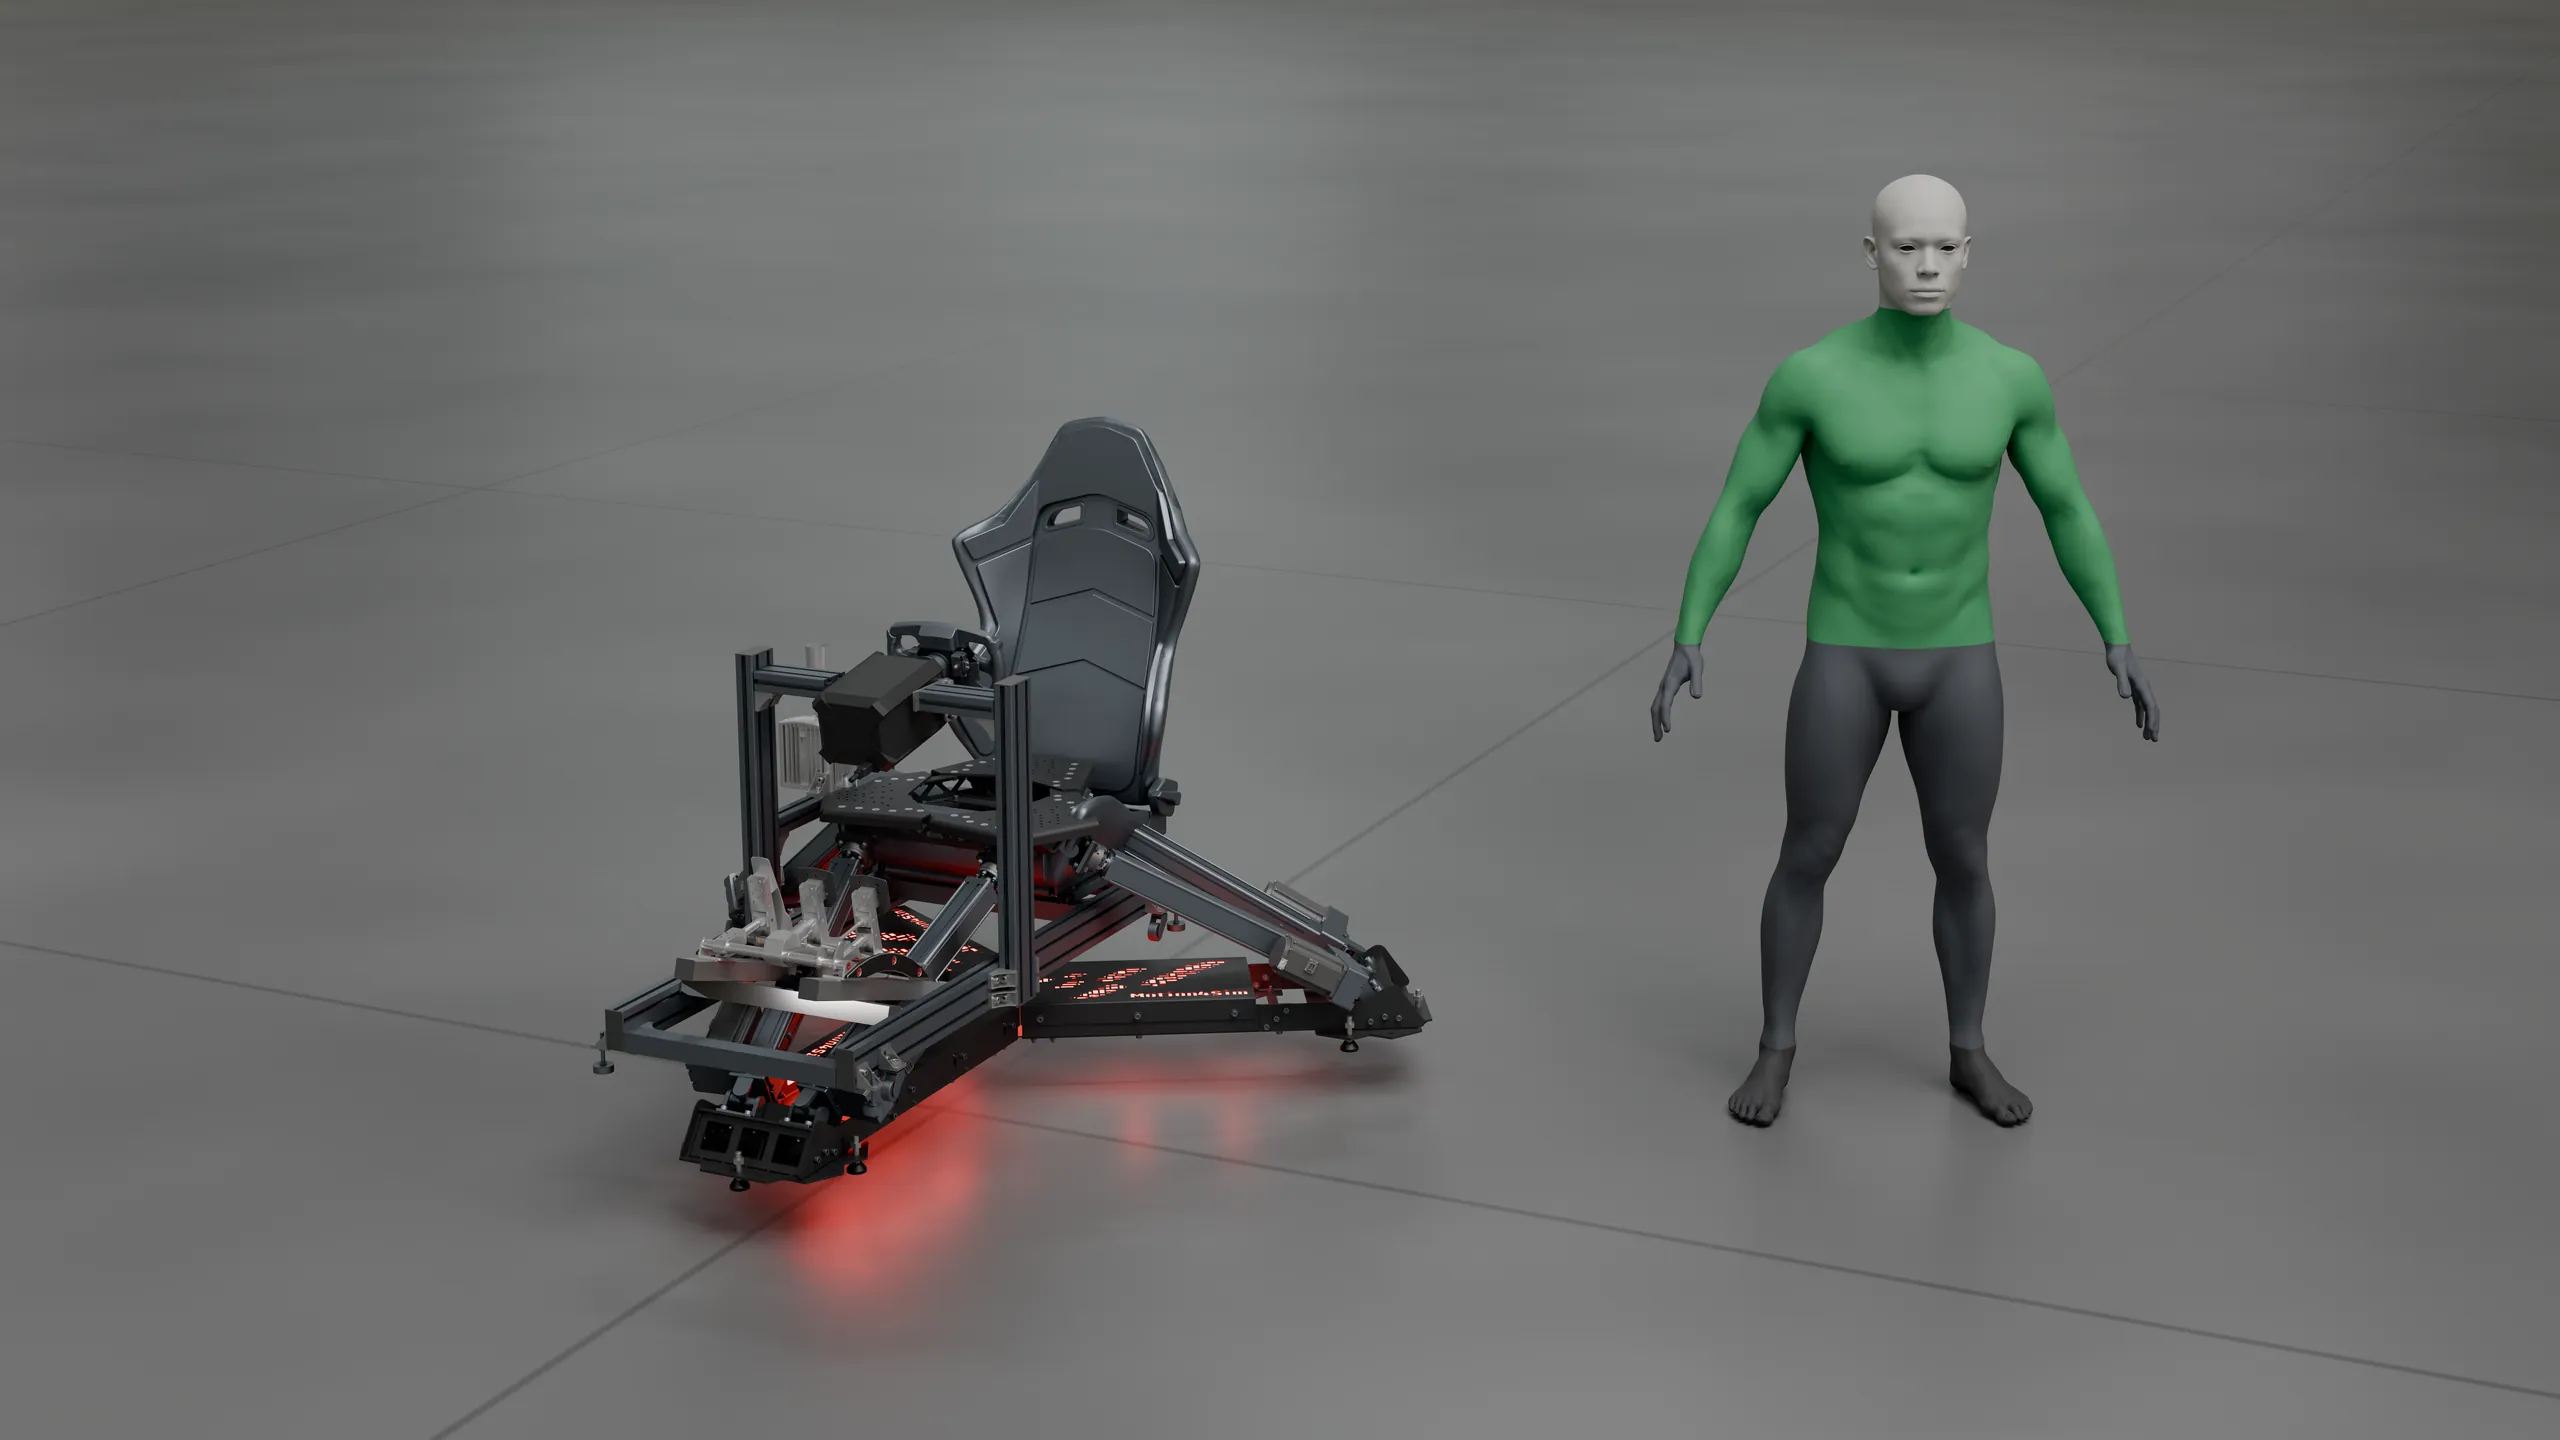
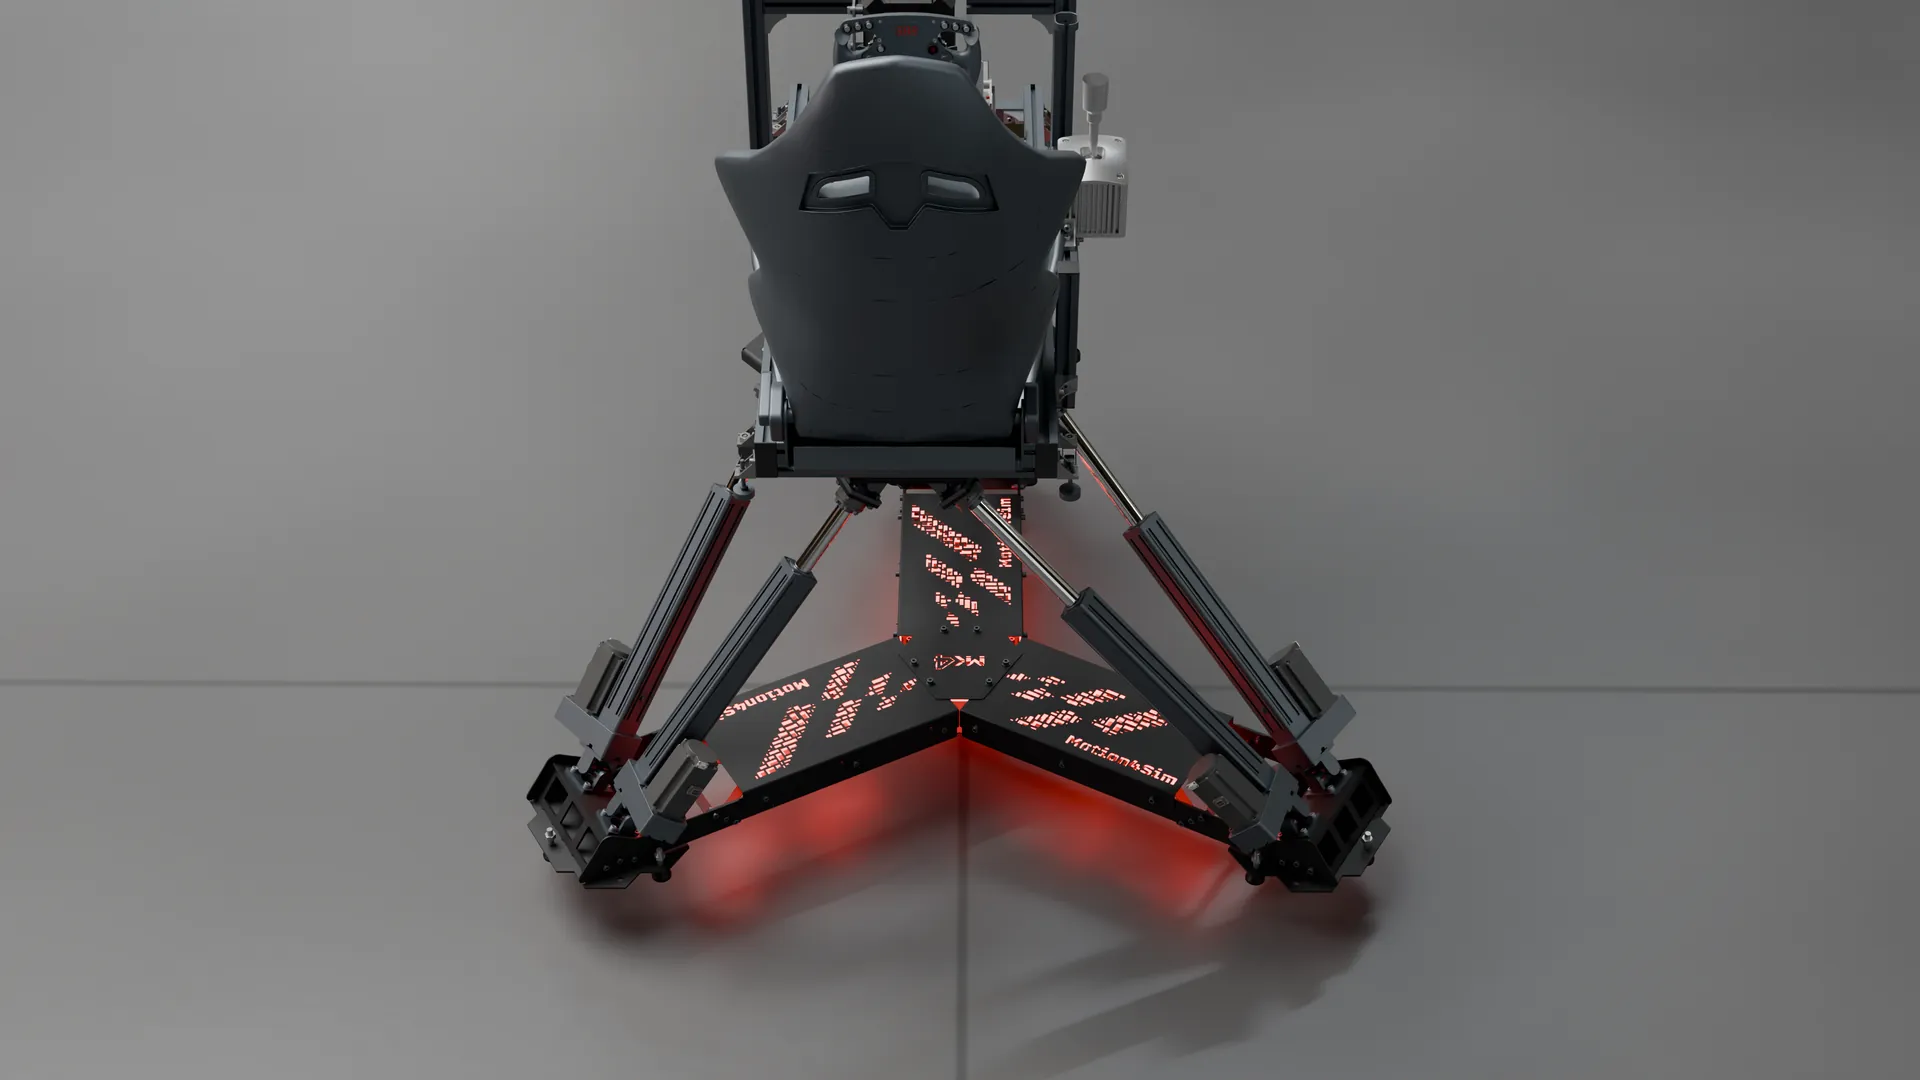
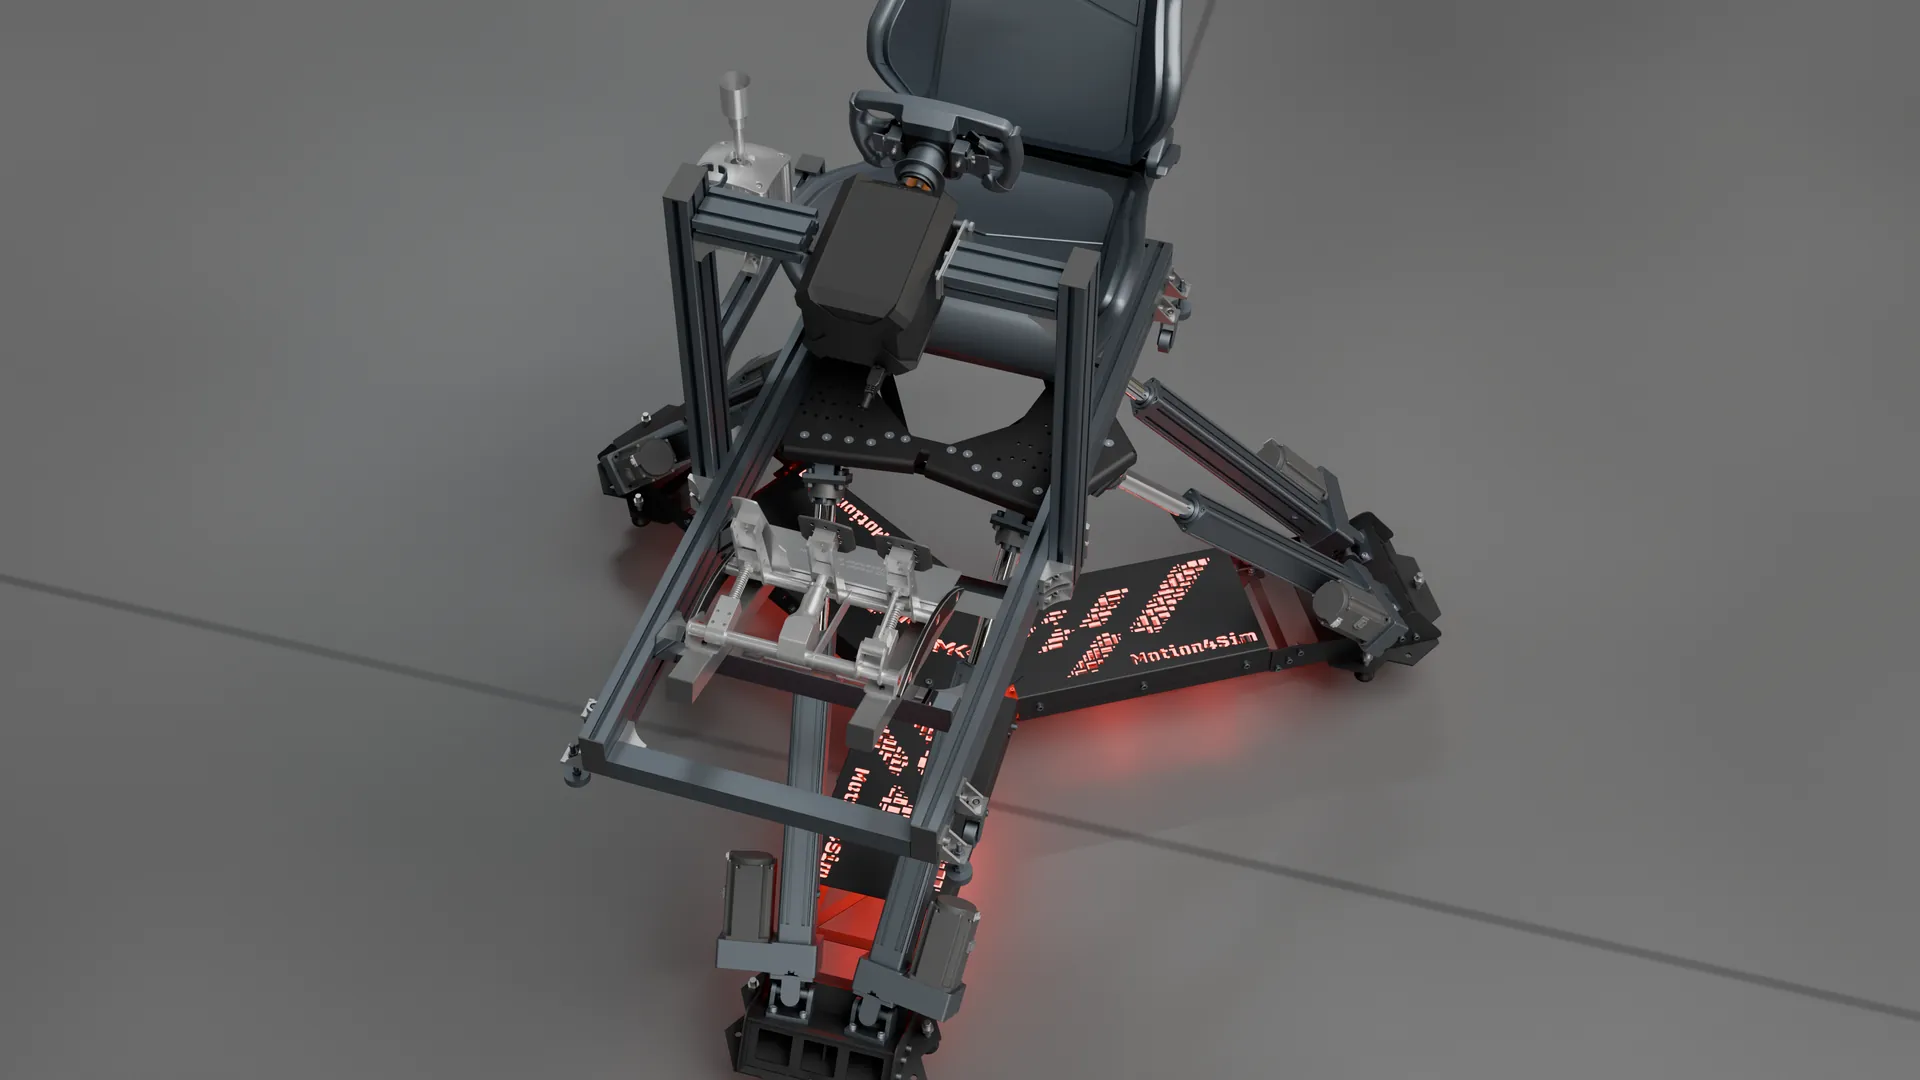
Prototype
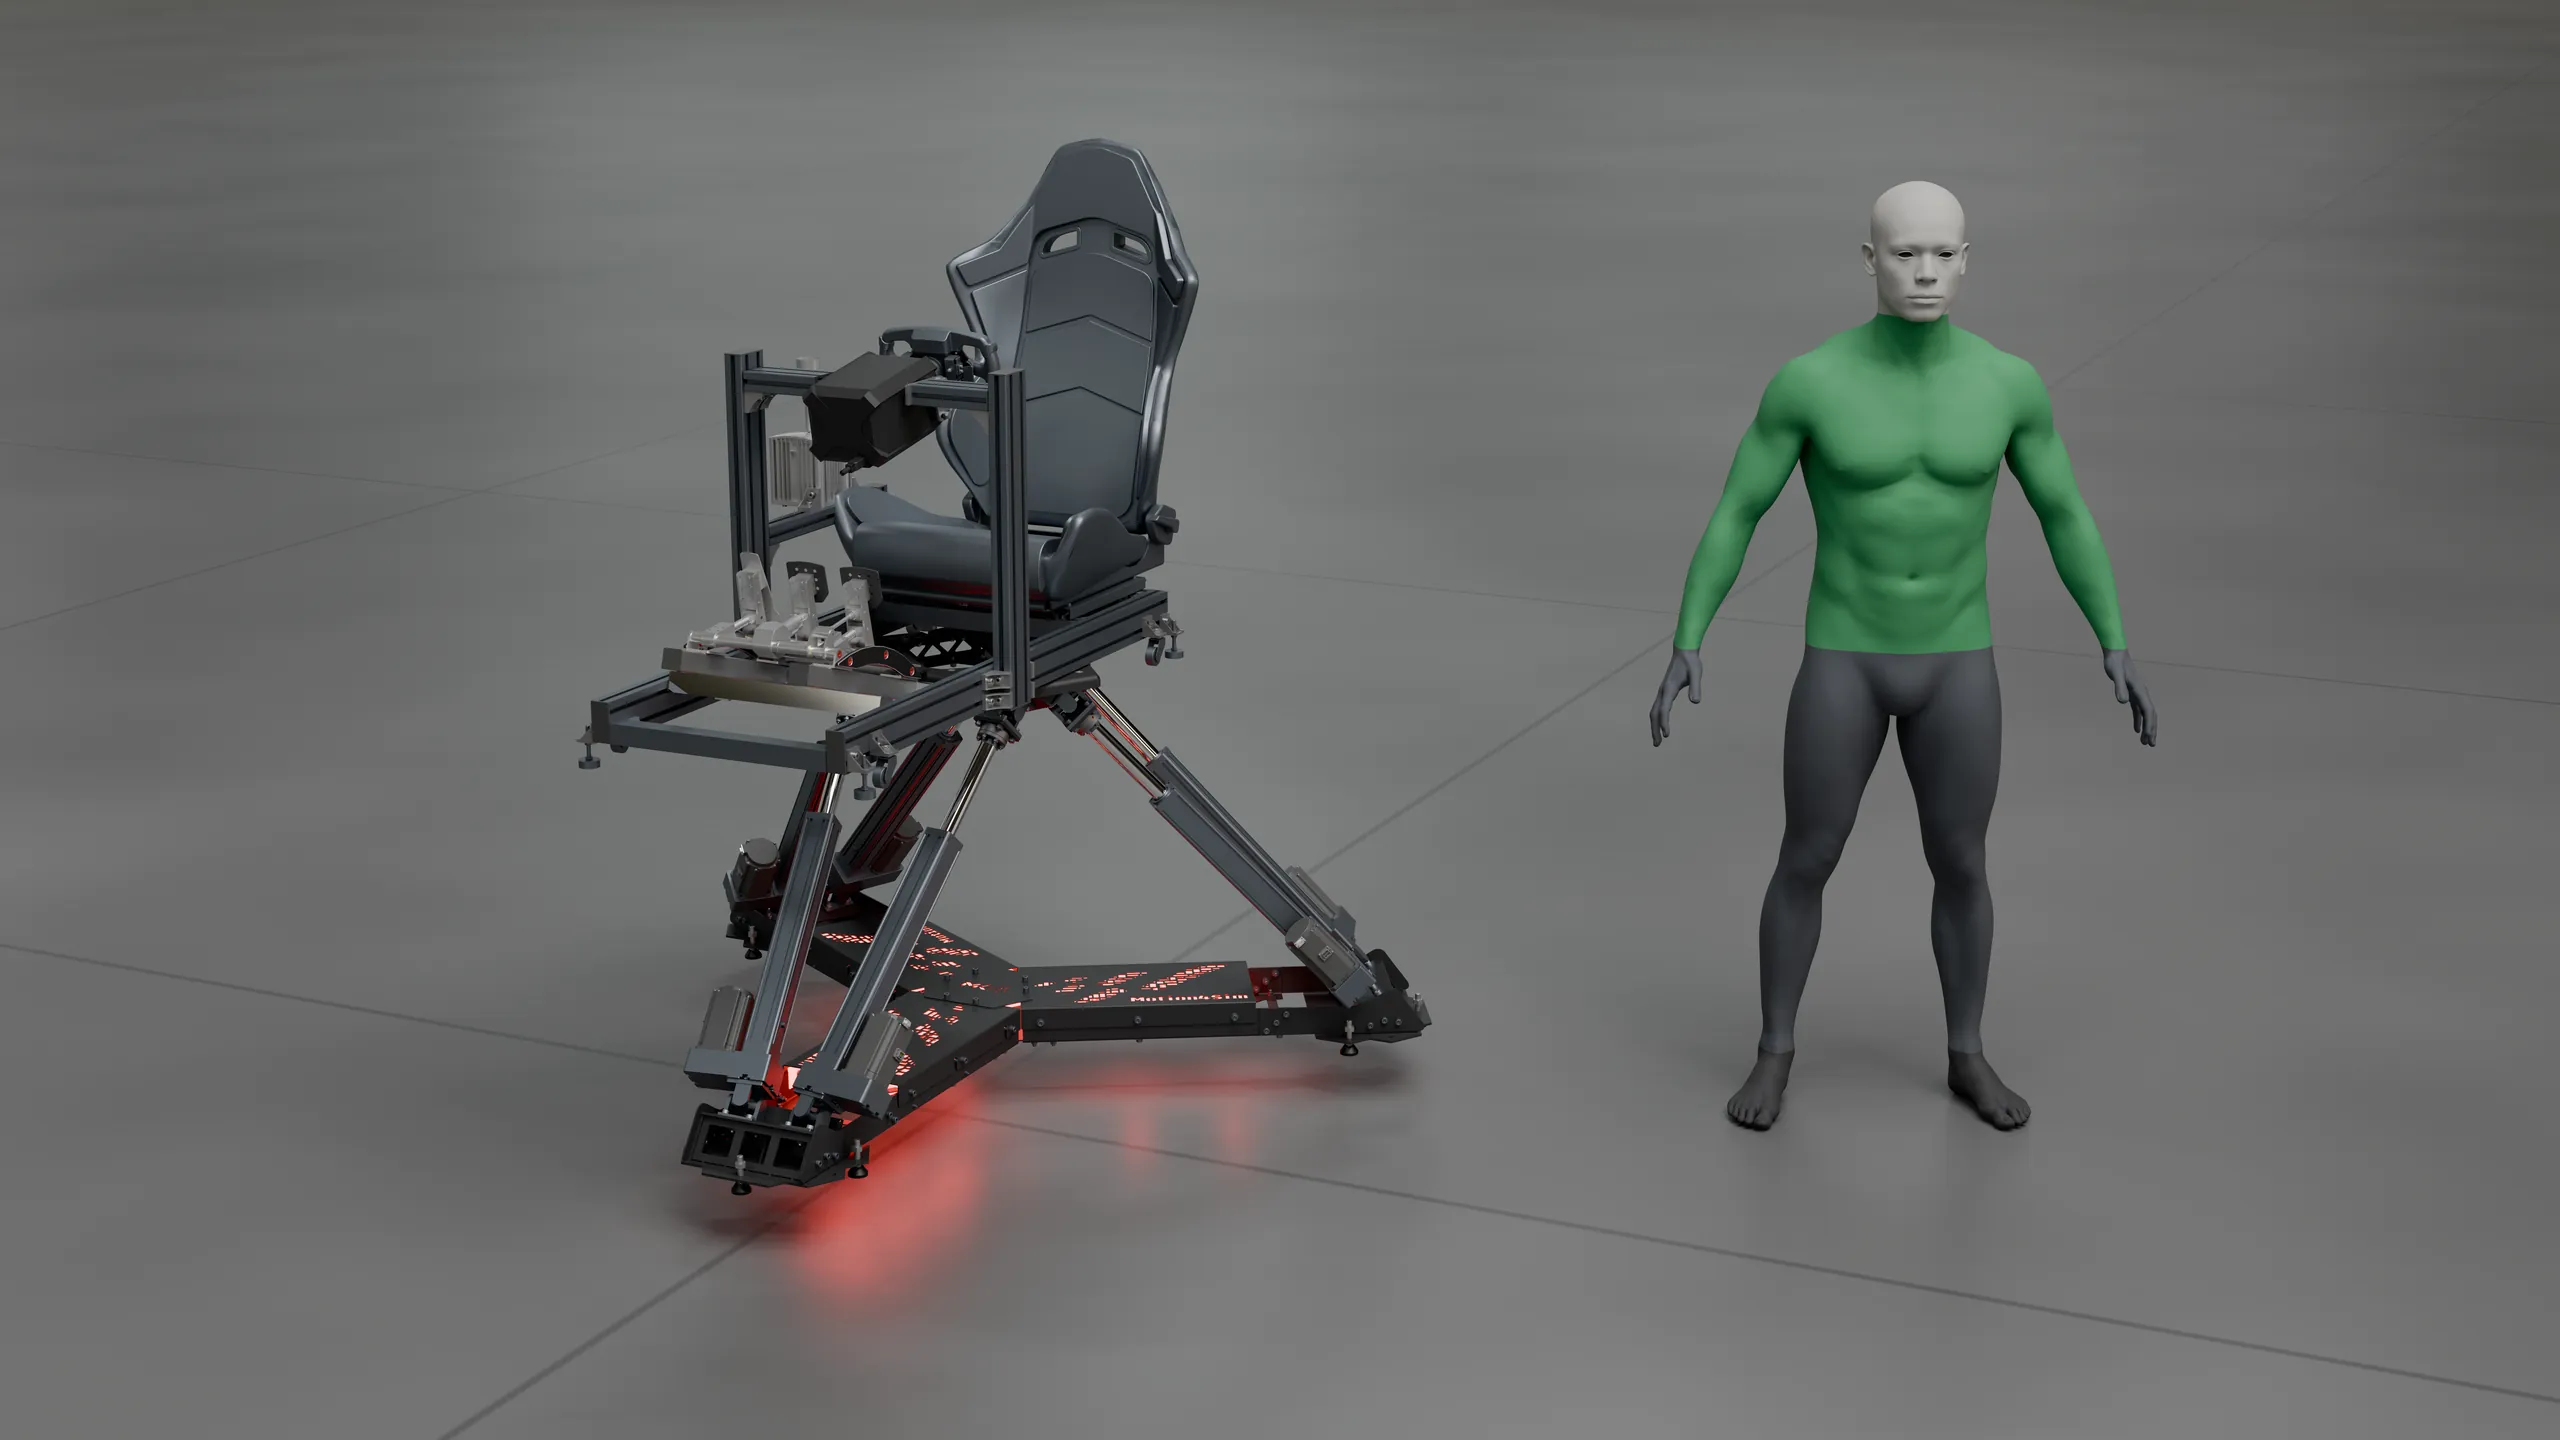
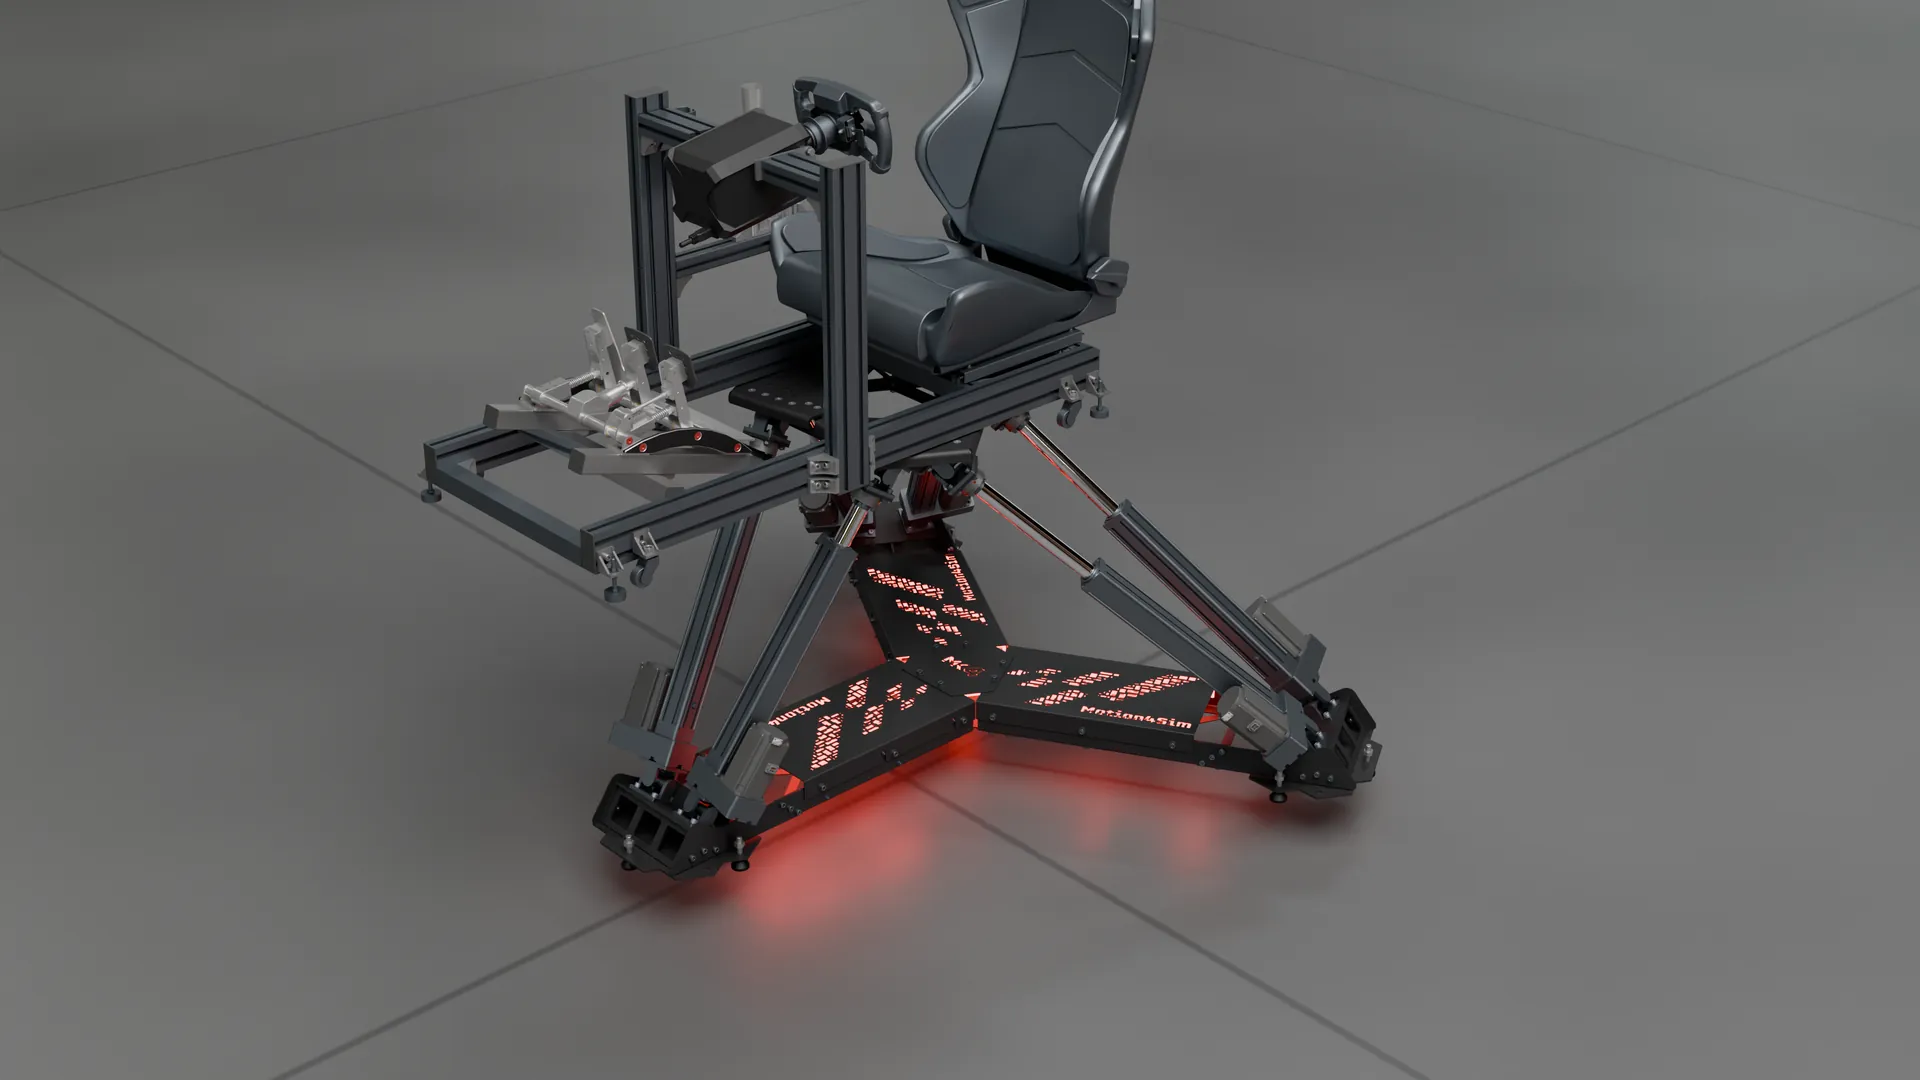
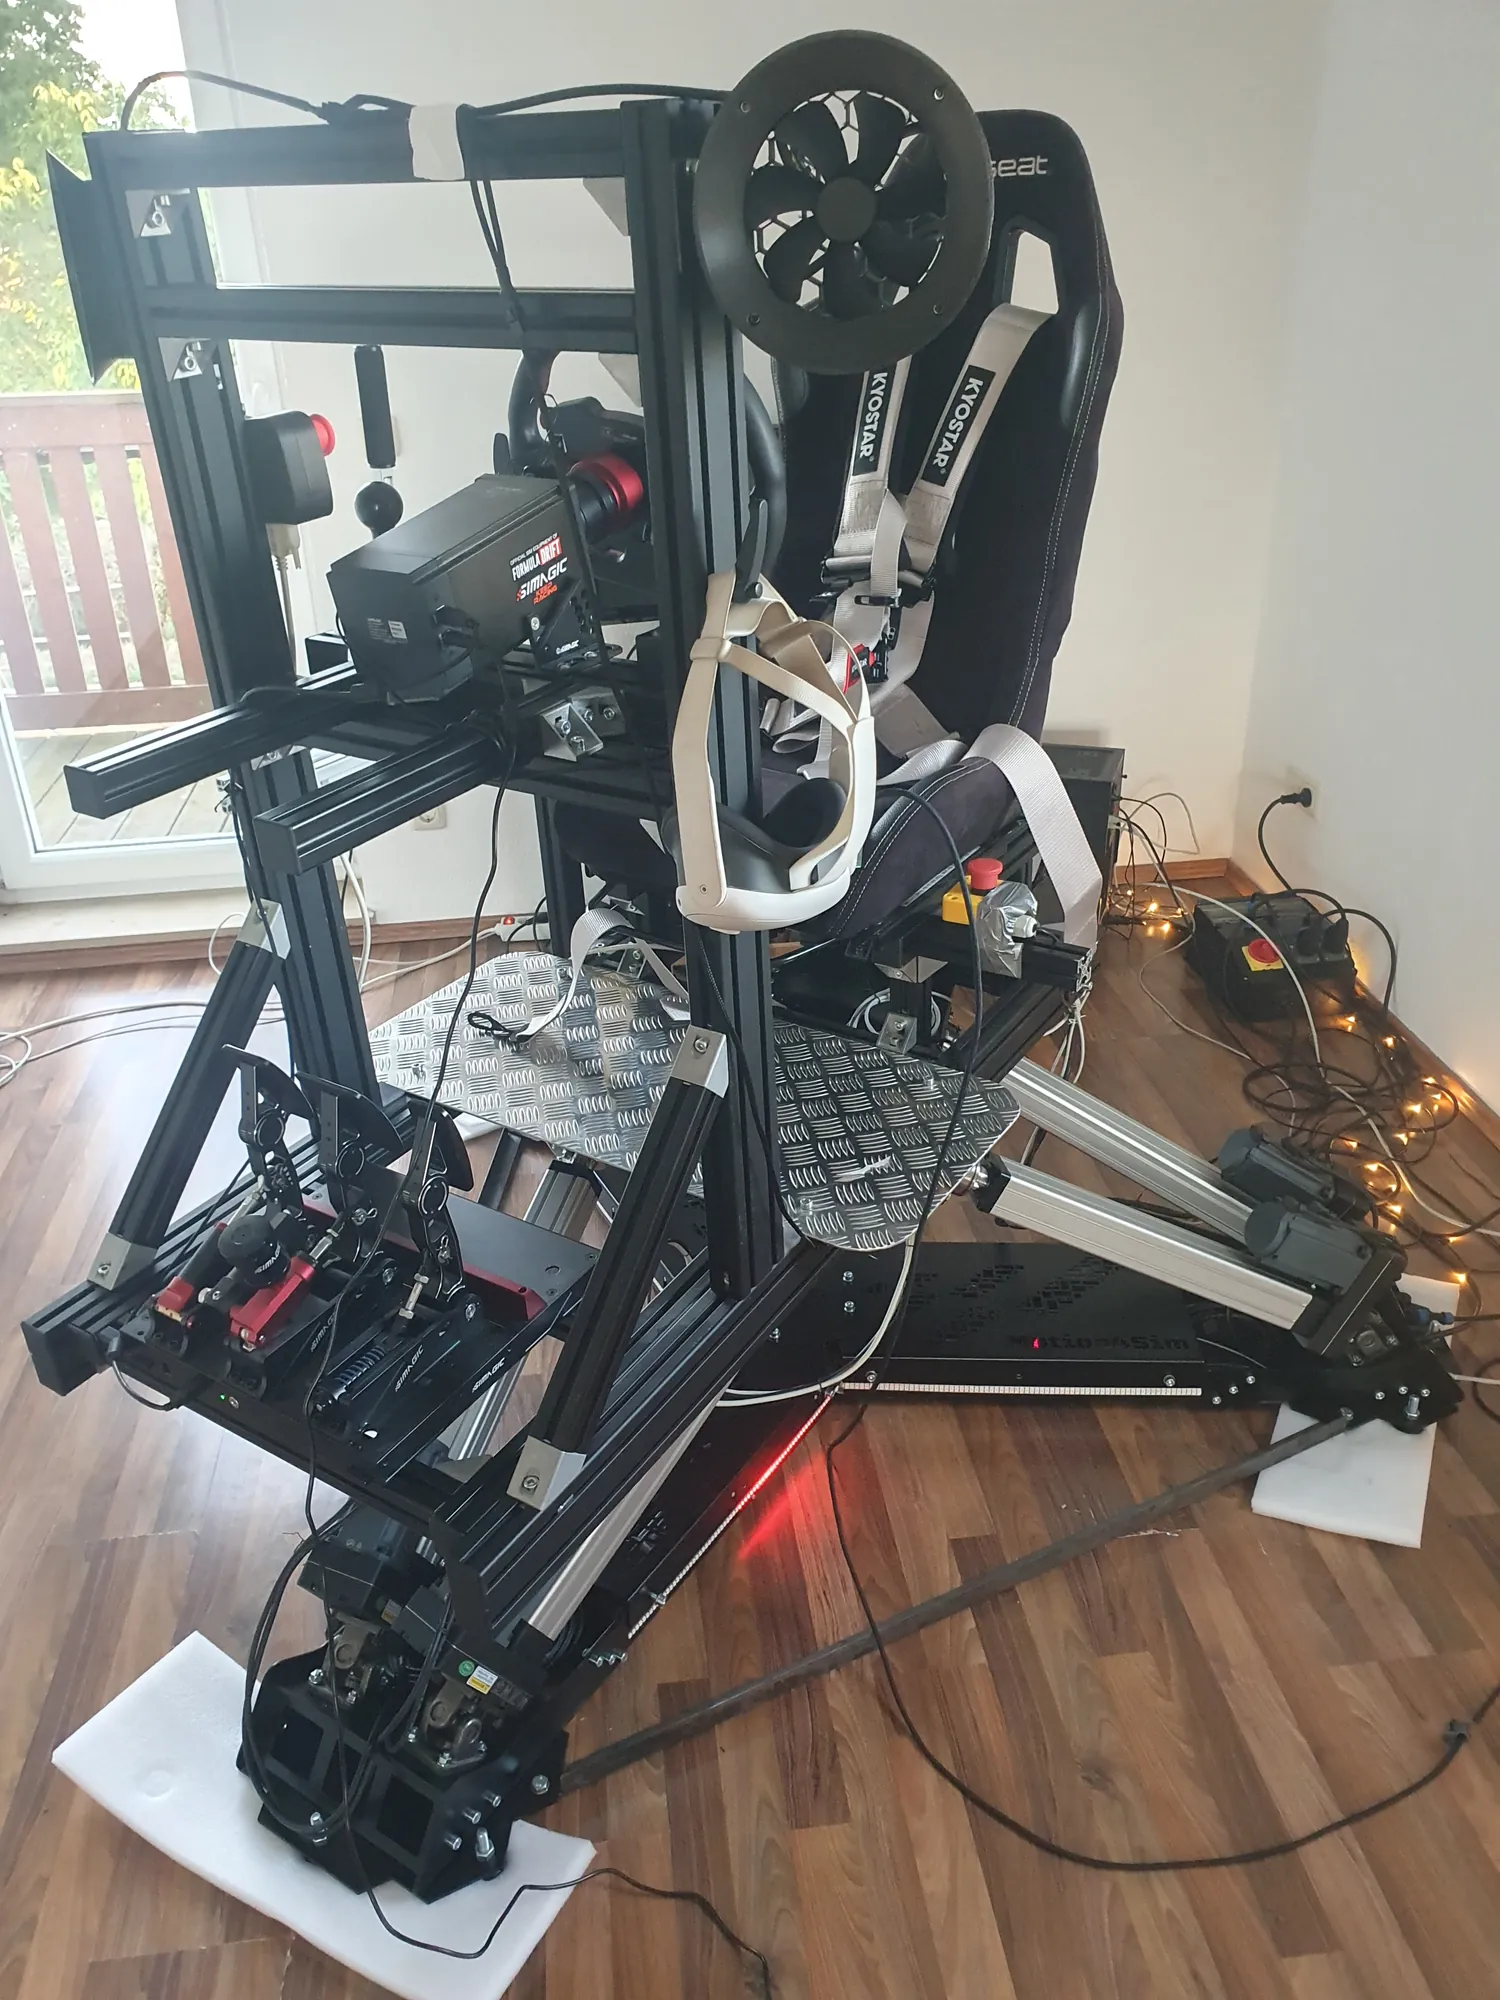
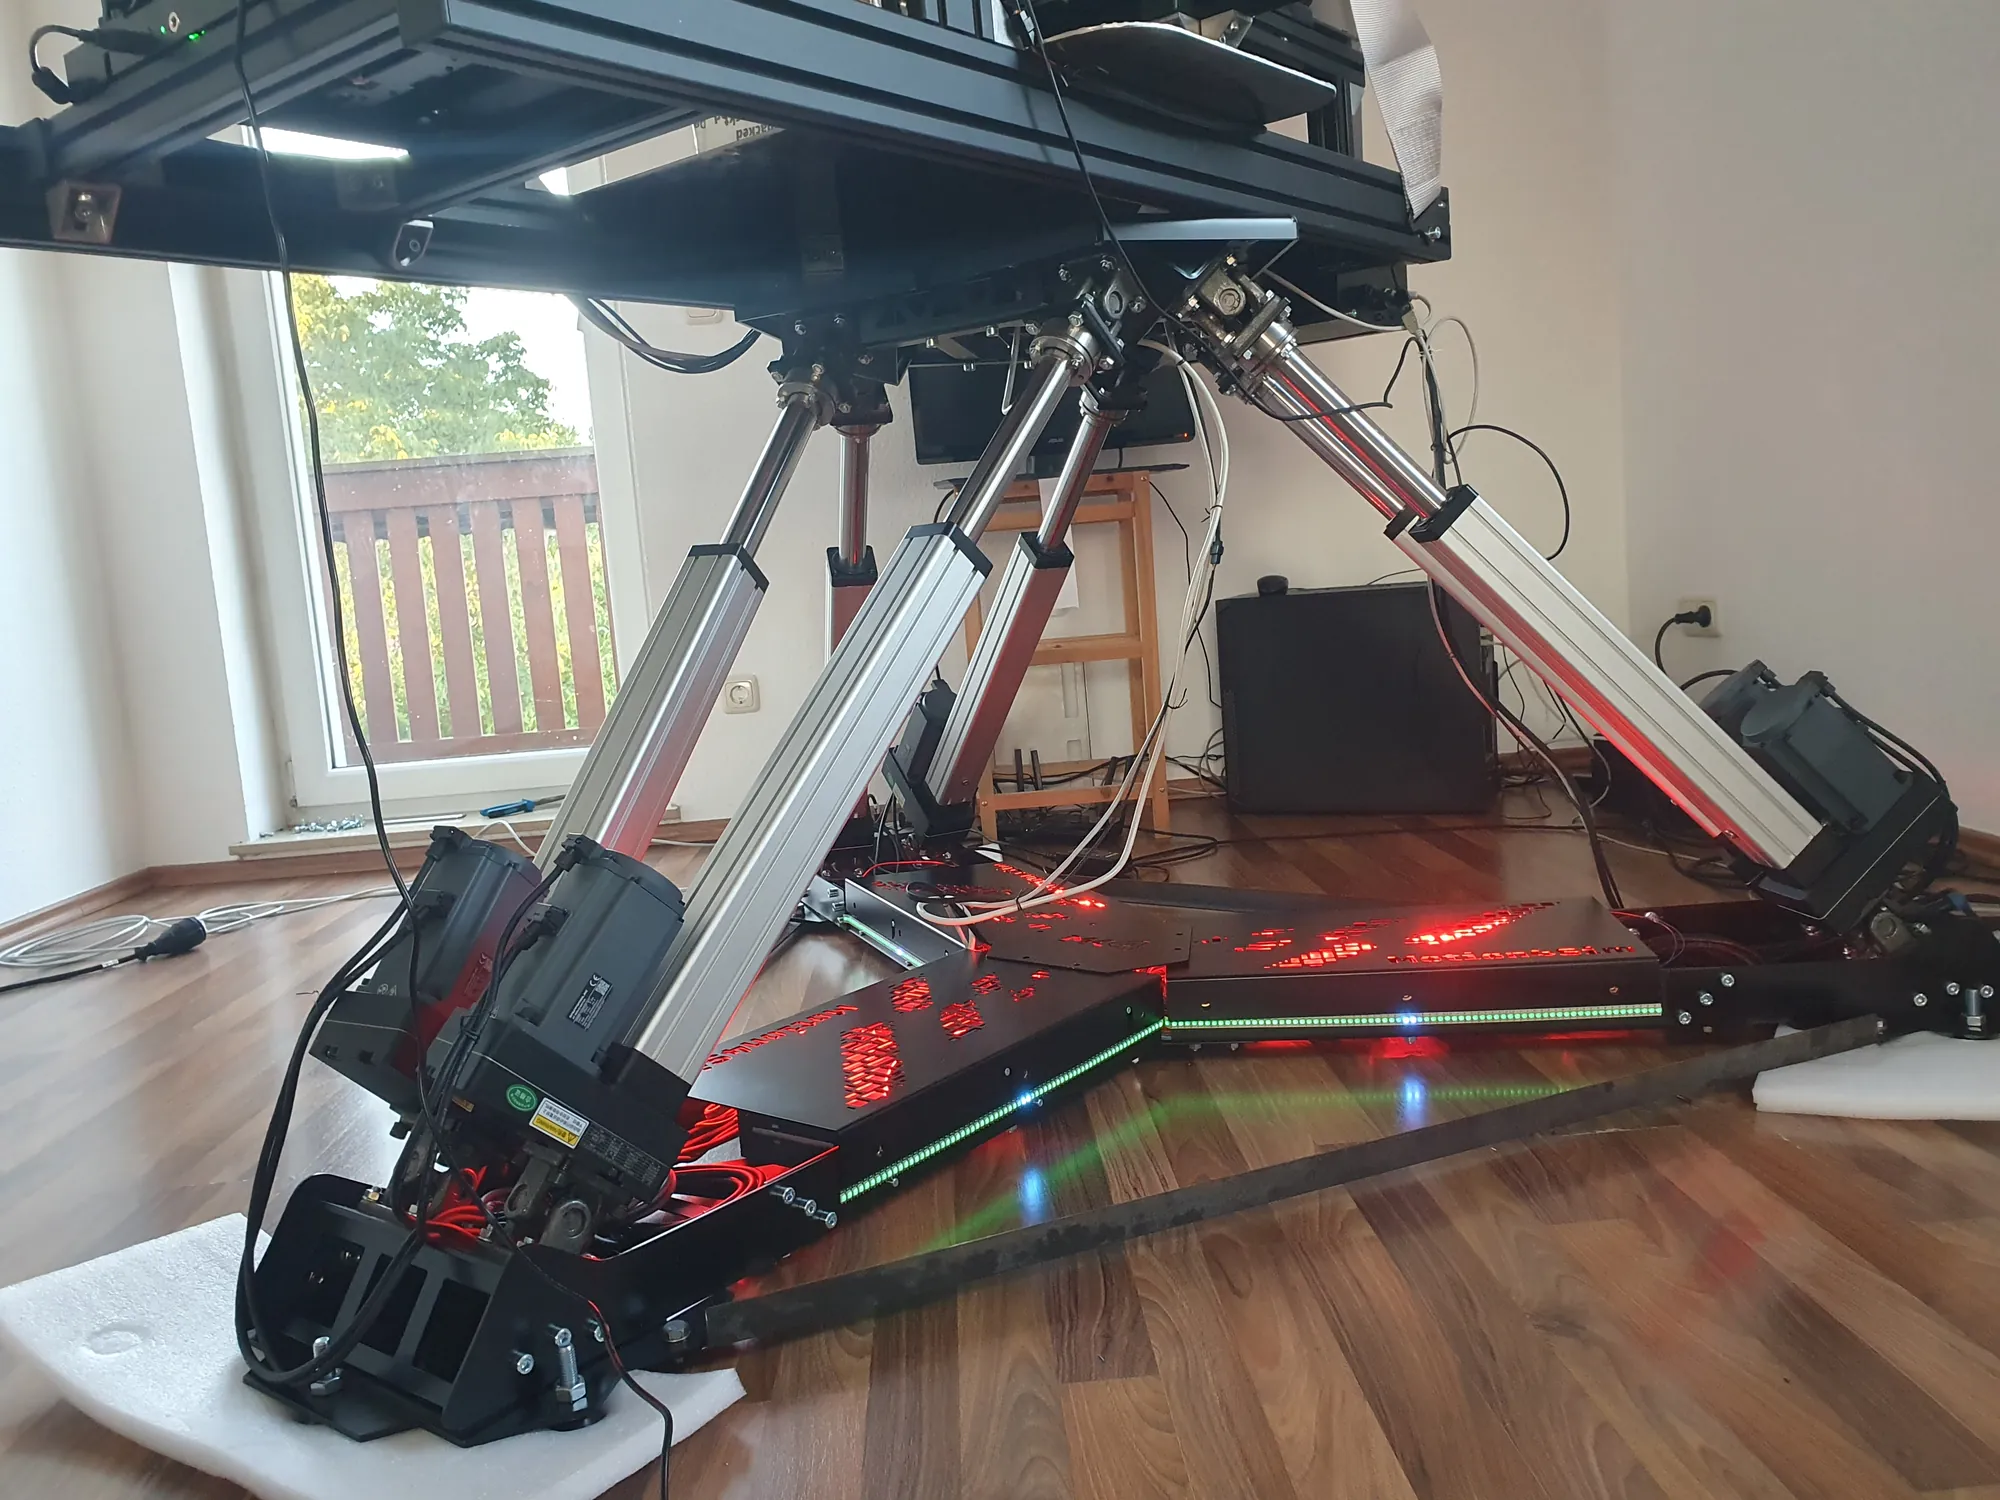
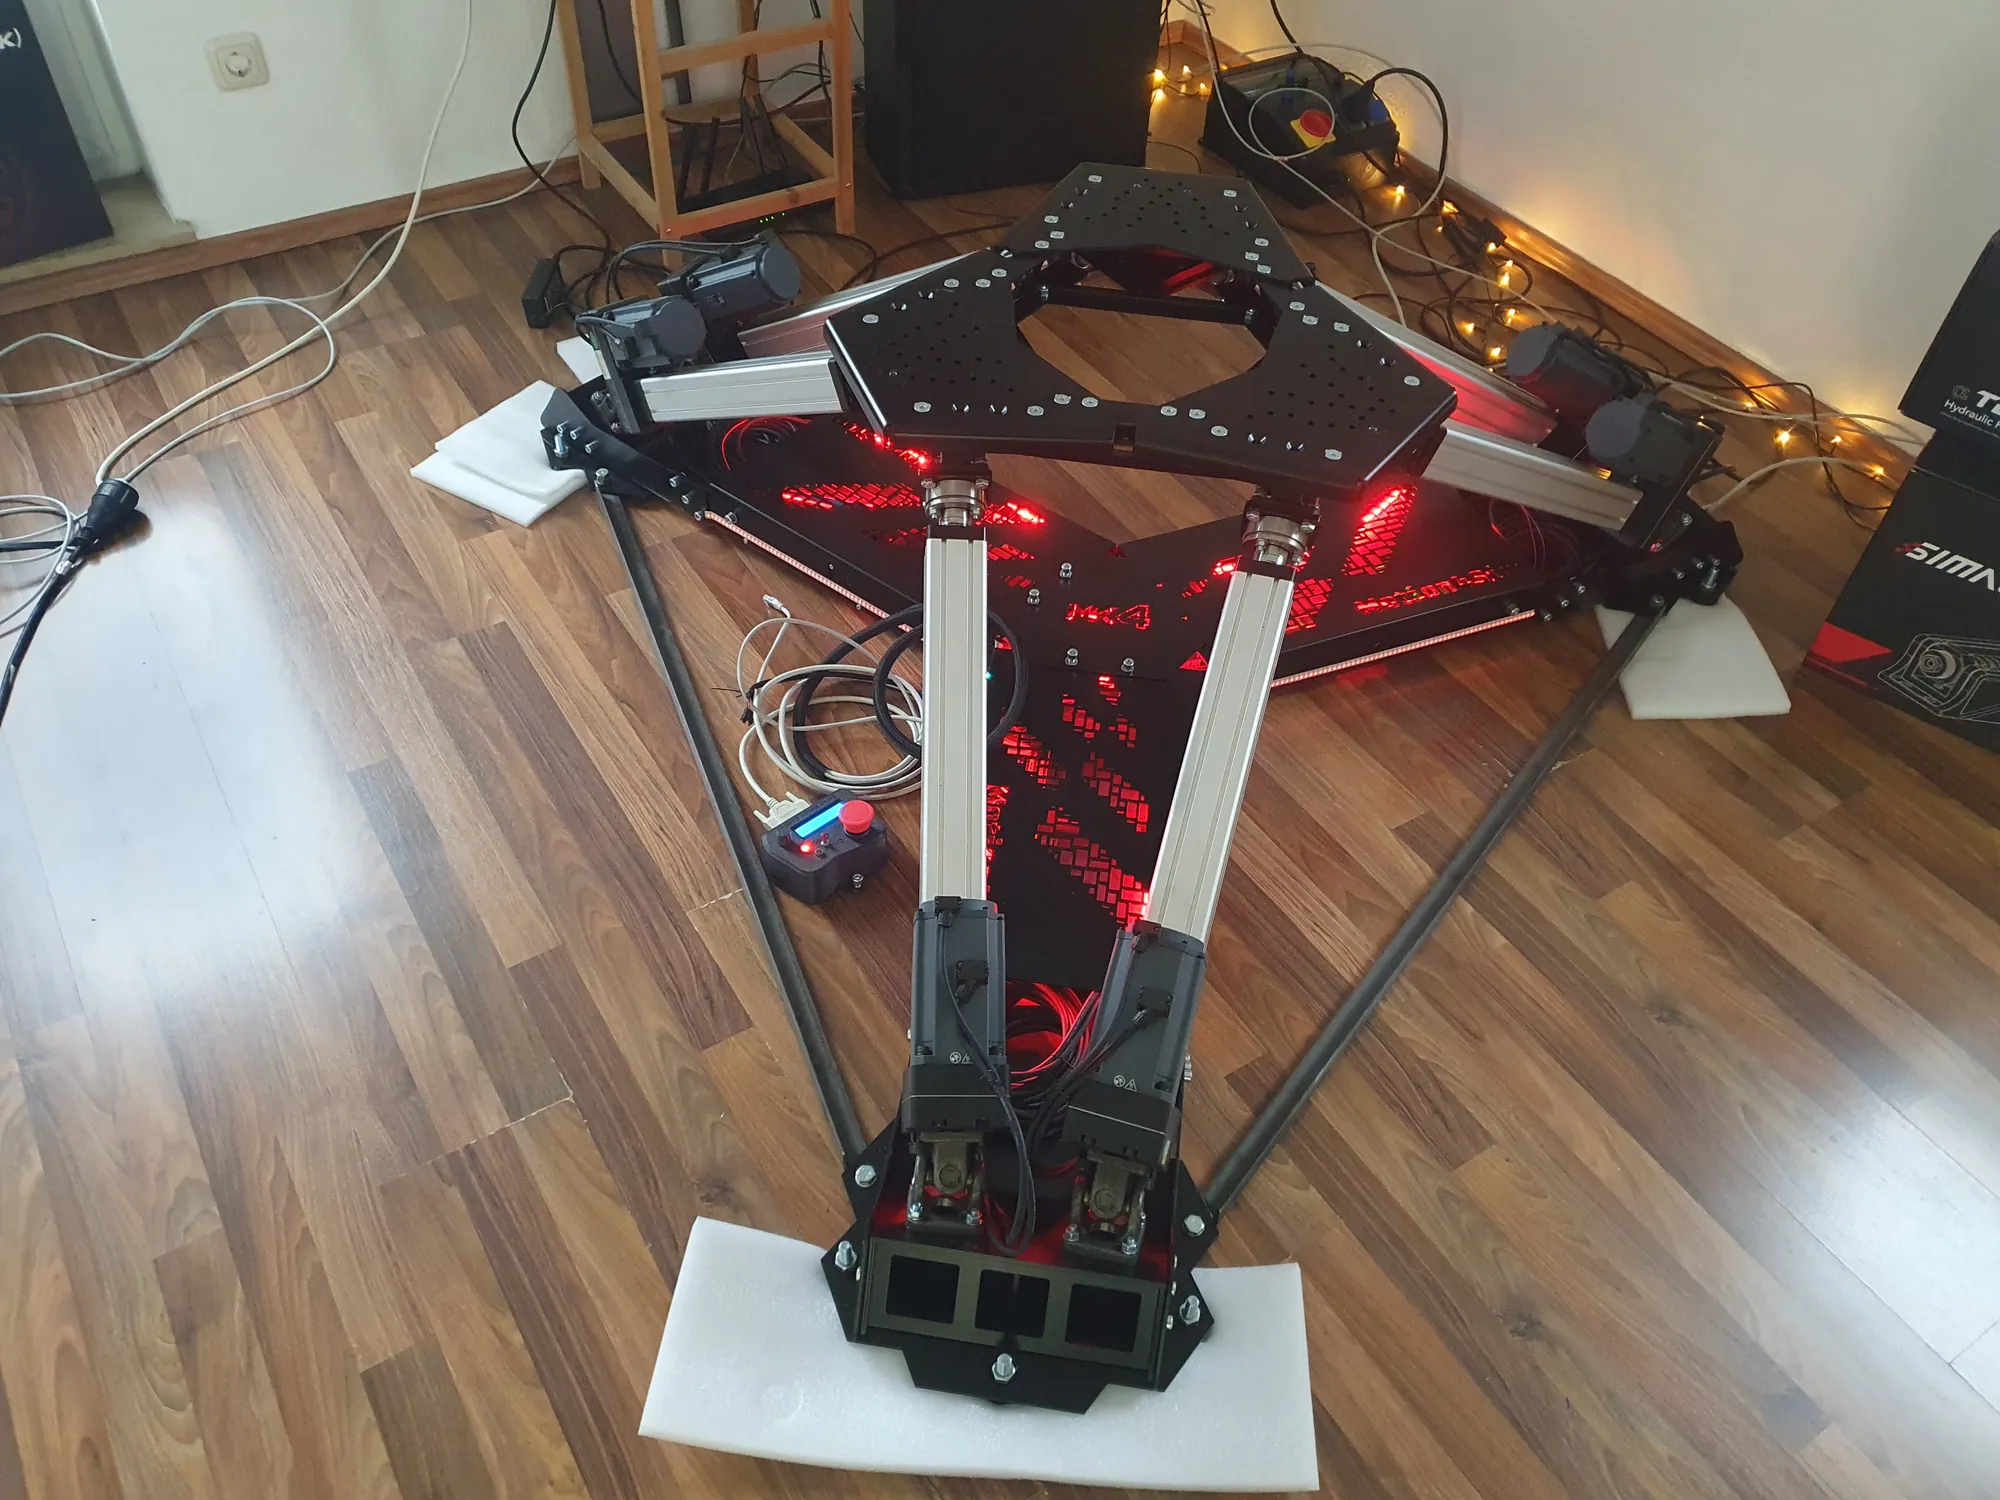
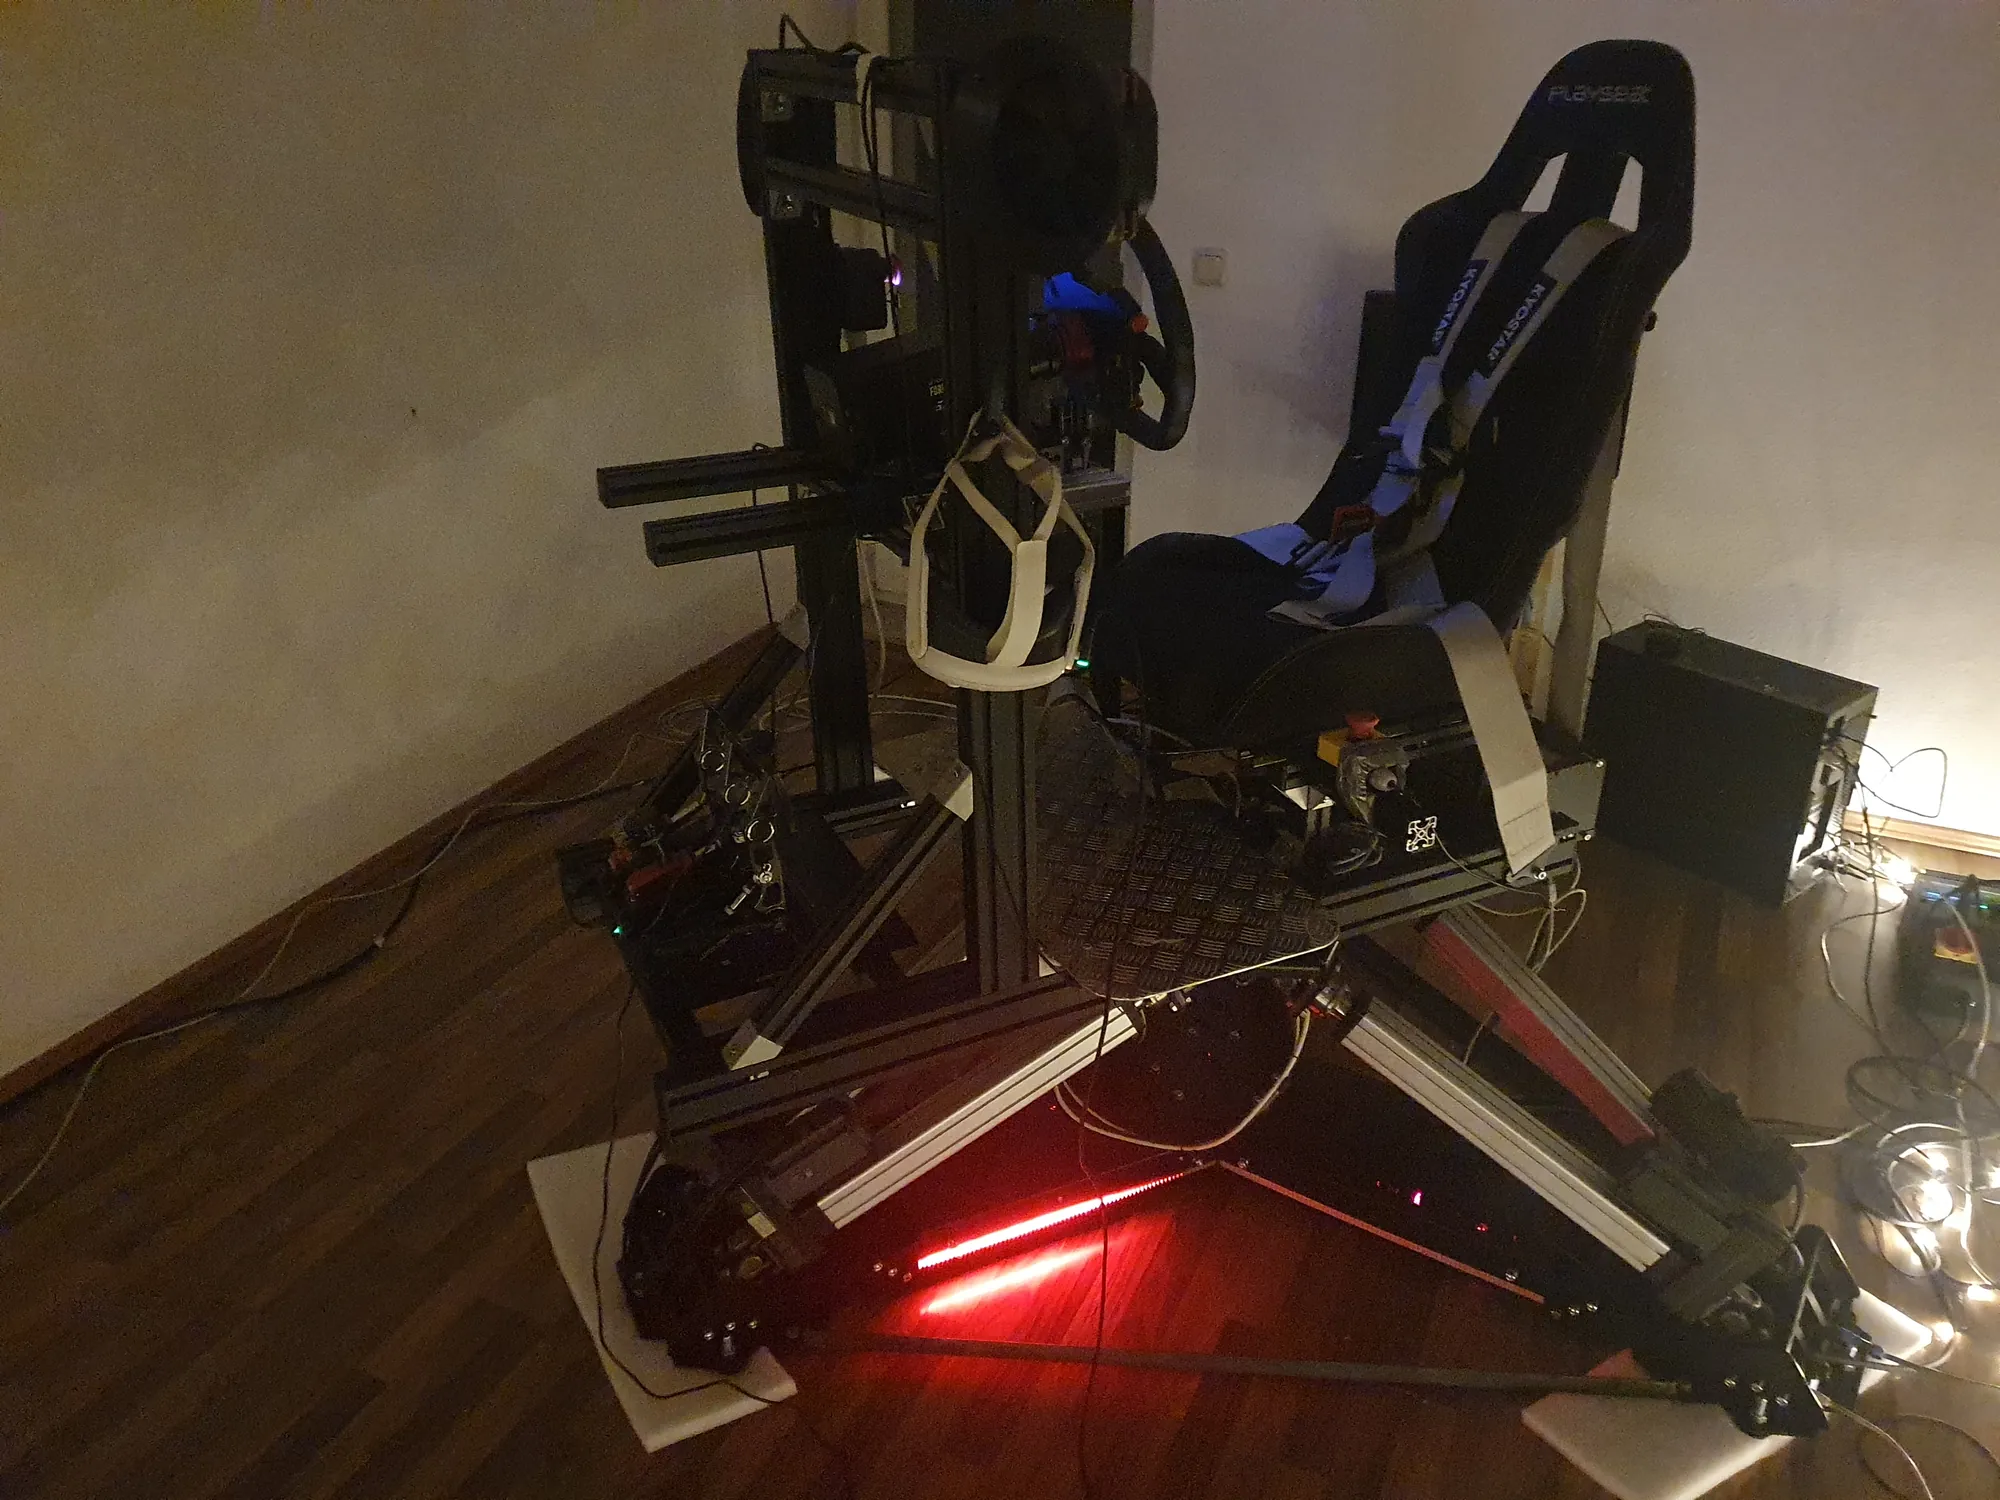
The first MK4 prototype under test — pictures straight from development, October 2026.
Technical data
Controller & software
The MK4 runs on the Motion4Sim controller. The Dashboard ships with an MK4 preset — geometry, actuators and limits are already set, and the 3D view shows your rig live.
Motion data comes from the cueing software you already use.
FAQ
The base covers 1745 × 1539 mm. With the cockpit shown and every axis at its limit, the platform sweeps an area of 1745 × 2378 mm — the dimension drawings above show the exact sizes in every position.
The top deck has an M8 threaded hole pattern for aluminium profile cockpits. The cockpit in the pictures is an example set-up.
The payload is calculated and planned at 200 kg on the platform — cockpit, wheel base, seat and driver together. As the MK4 is still in development, this value is provisional.
Everything your motion software supports. The controller works with SimTools, FlyPT Mover, Sim Racing Studio and SimHub — see the documentation for the full list.
The 1000 W servos are fan-cooled and quite loud in their original form. A quieter modification is in development, but it would void the manufacturer's warranty. Passively cooled 750 W servos are quiet, but allow less payload.
All six axes have holding brakes. The platform stays where it is instead of sinking down.
Tell us about your set-up — we will get back to you with availability and pricing.